FoundationVIO: Enforcing Metric Scale in Feed-forward Visual-Inertial Odometry
Jin Rhee, Yuhao Zhang, Frank Dellaert, Maurice Fallon

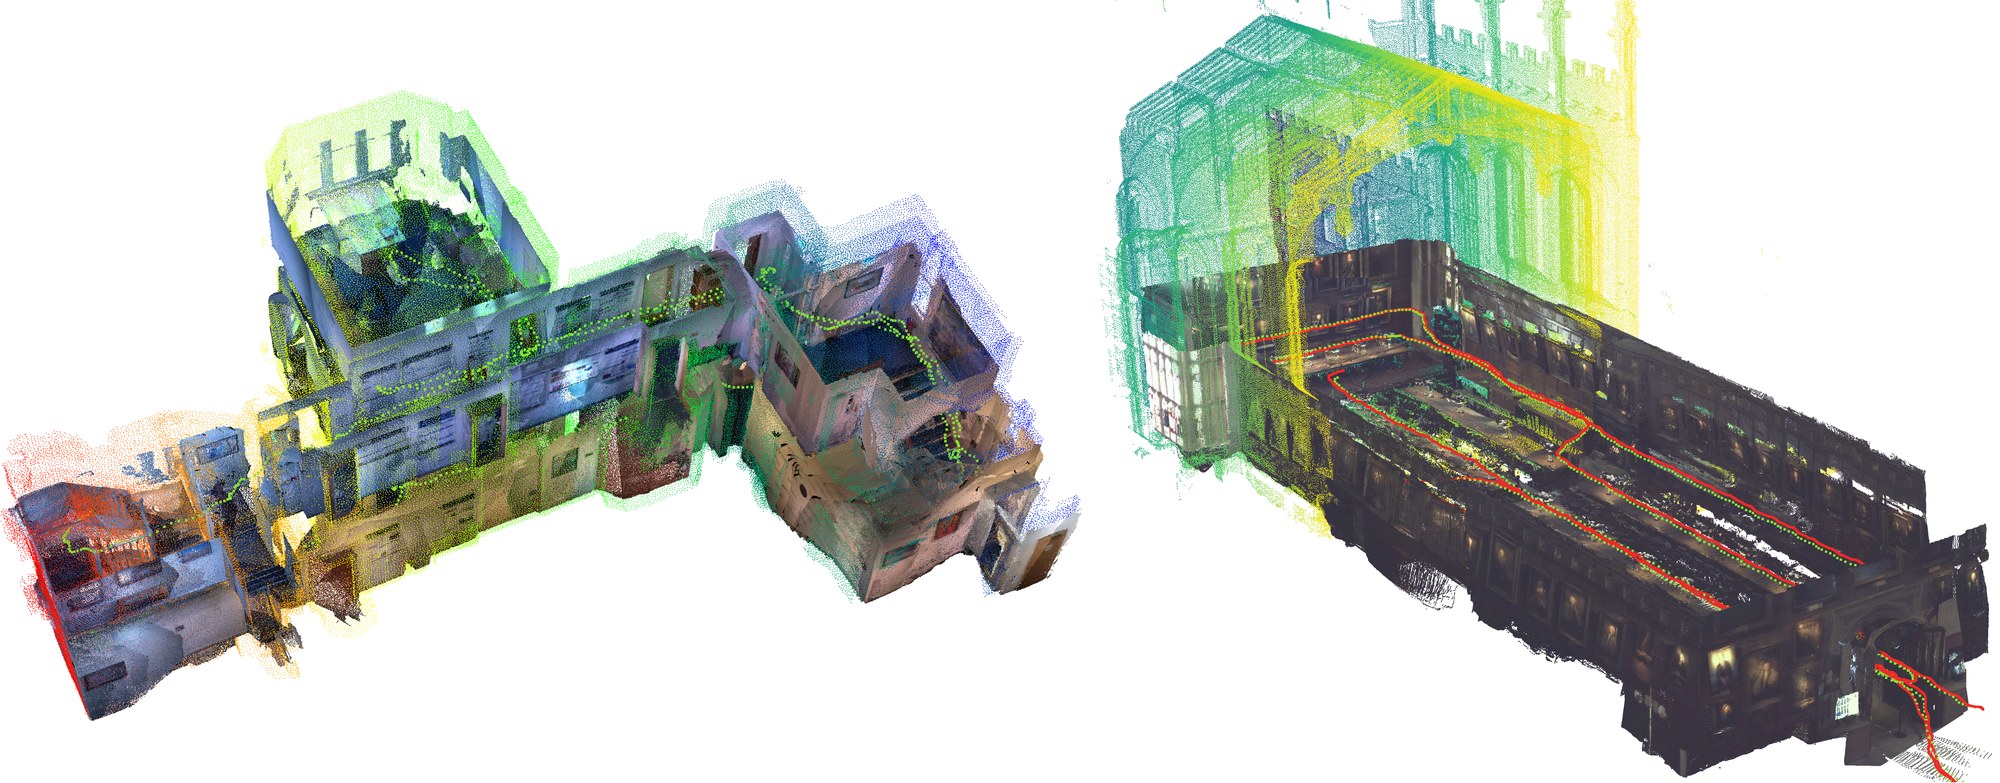
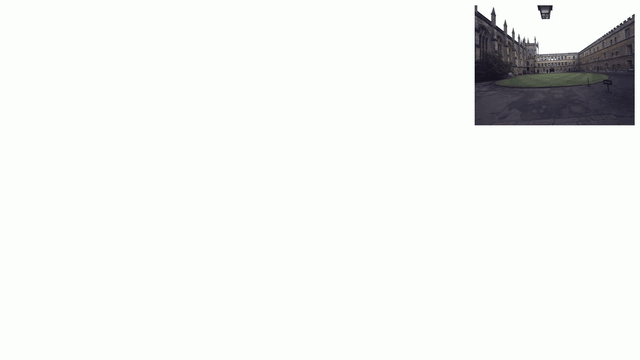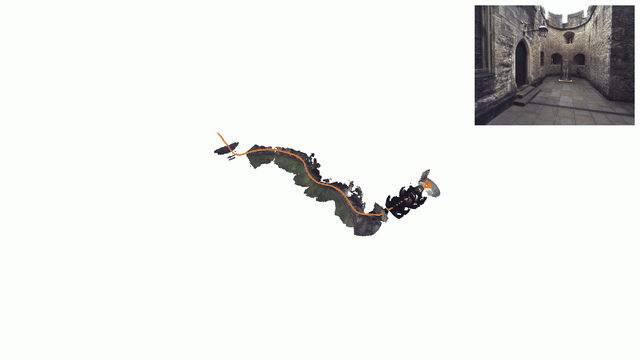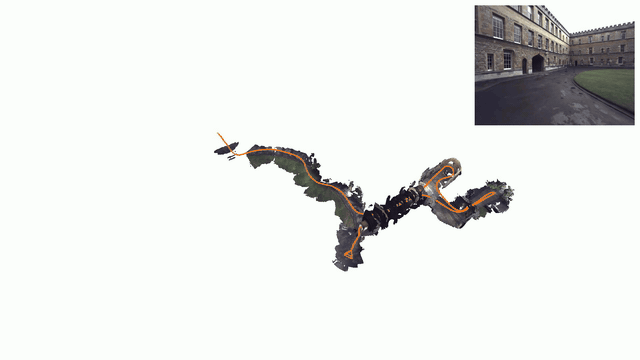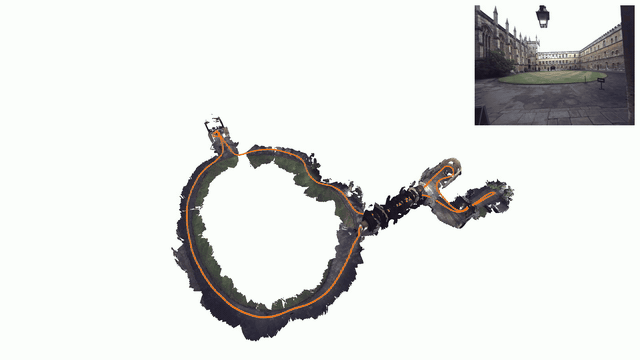
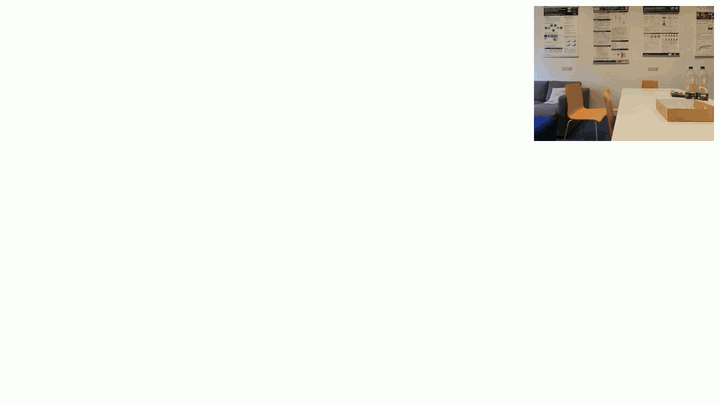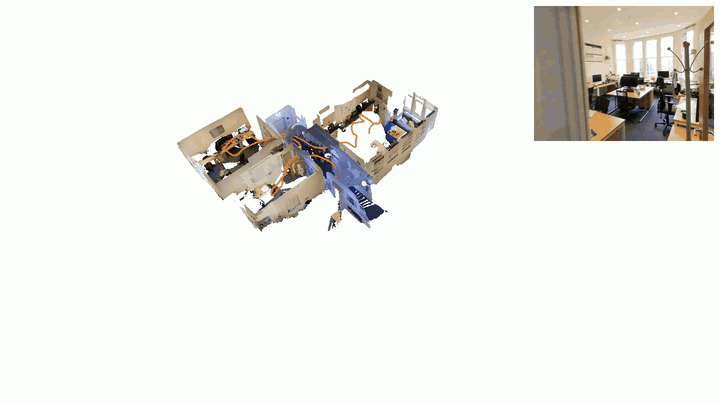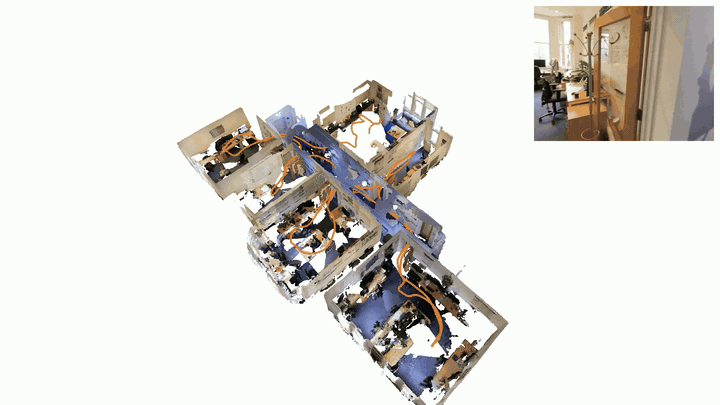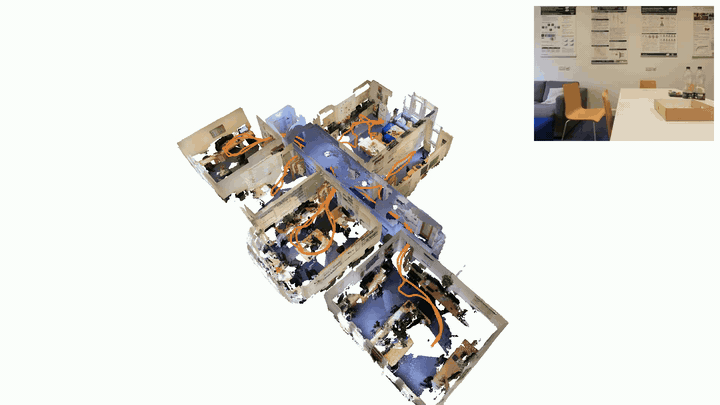
FoundationVIO is a visual-inertial odometry method that fuses inertial sensing with learned geometry from general feed-forward 3D geometric foundation models (GFMs) in a factor-graph based optimisation. Due to its use of a GFM and inertial sensing, FoundationVIO is able to 1) remain robust in low-texture sequences that are challenging for classical methods and 2) enforce metric scale in odometry estimates and reconstructions.
Description
We additionally add GFM-based initialisation and loop-closure to demonstrate globally accurate trajectories and reconstruction. The method is compatible with general N-view GFMs such as DepthAnything3 and VGGT-Omega and naturally profits from advances in model accuracy and speed.
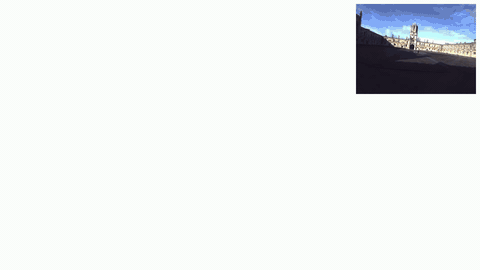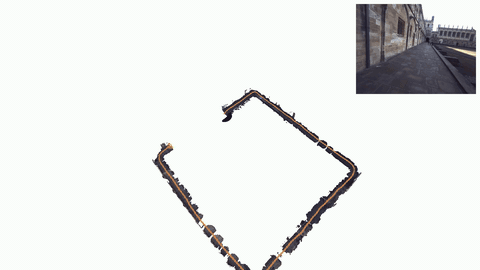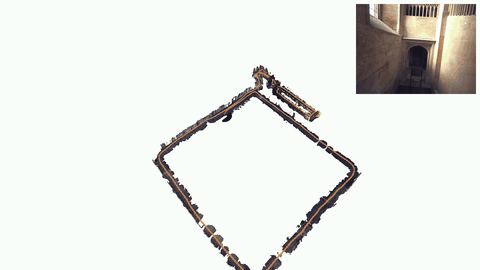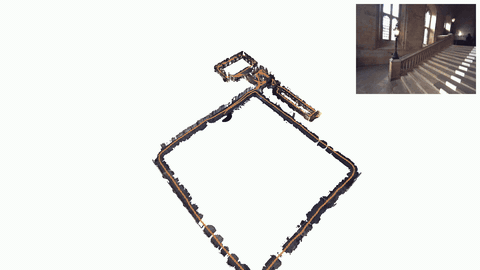
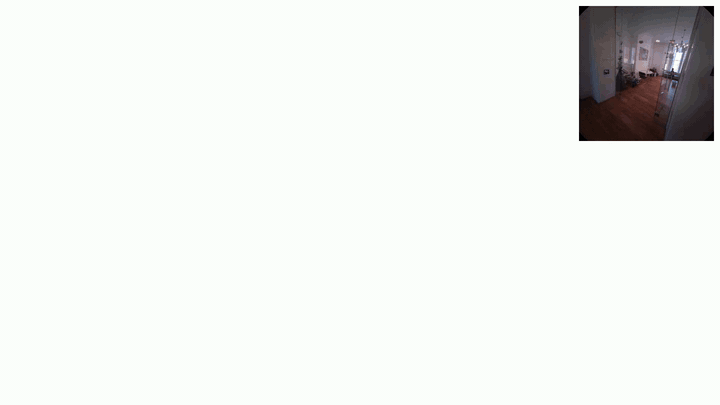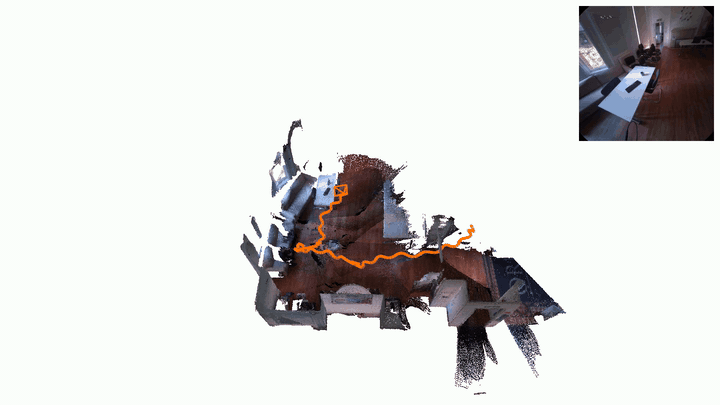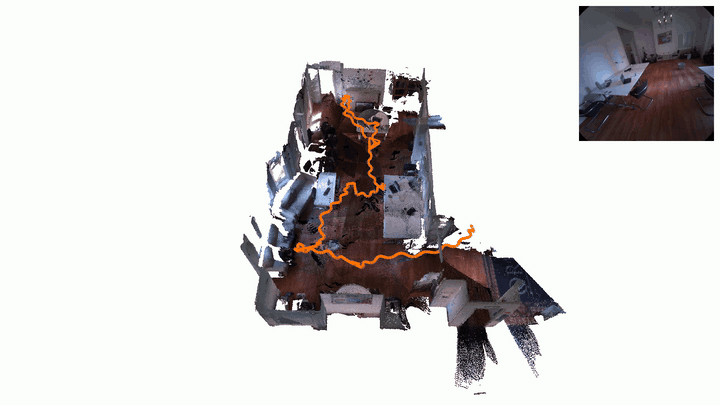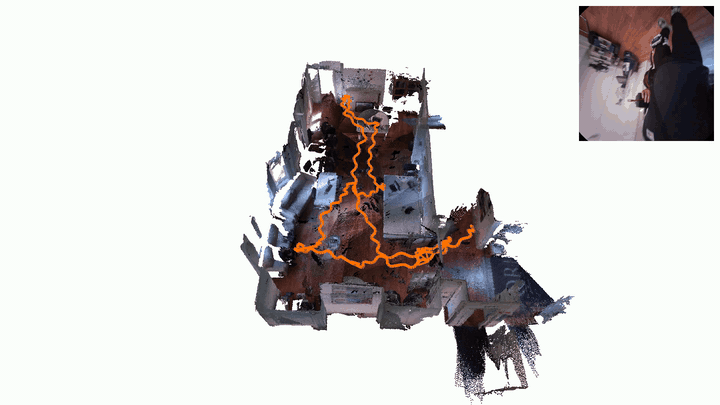
Method Overview
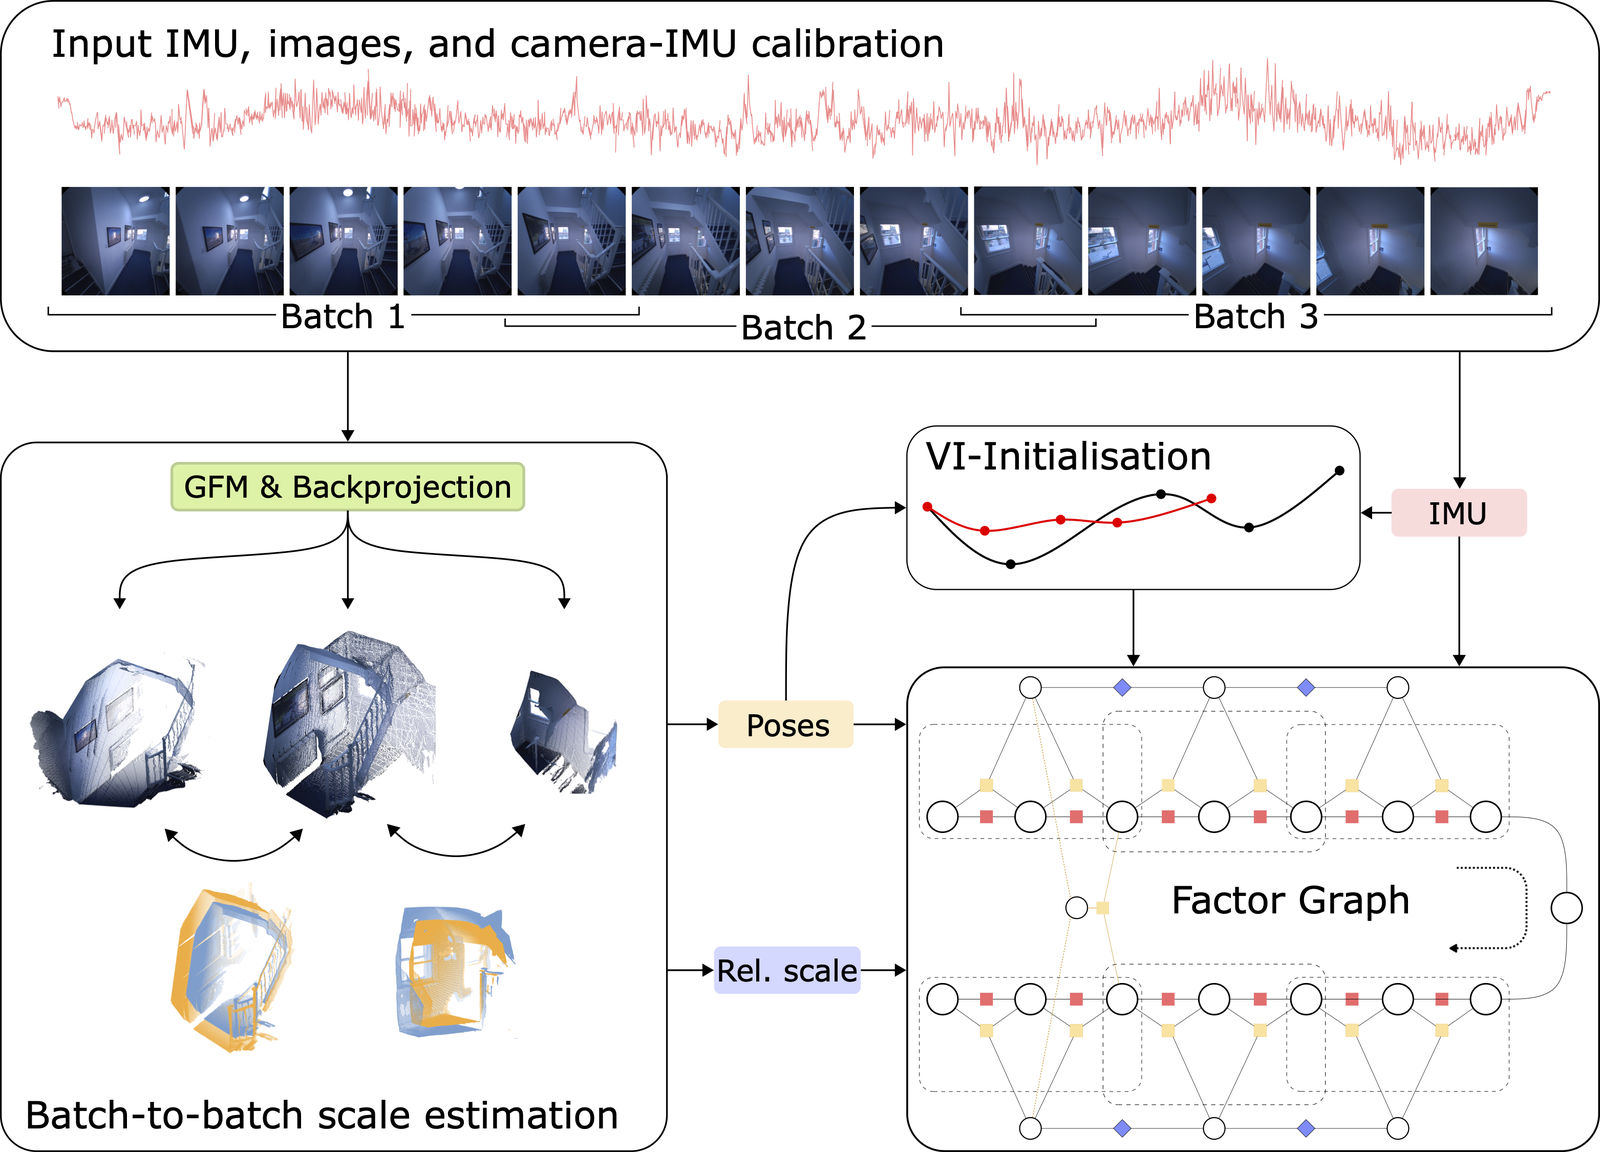
Each batch of images is passed through the GFM, and the predicted relative poses enter a factor graph as scale-pose factors tied to a per-batch scale variable. Preintegrated IMU factors constrain the same poses in metric units, so the optimisation recovers the metric scale of every batch, and scale factors between consecutive batches keep it consistent along the trajectory.
Citation
@article{rhee2026foundationvio,
  title={{FoundationVIO}: Enforcing Metric Scale in Feed-forward Visual-Inertial Odometry},
  author={Rhee, Jin and Zhang, Yuhao and Dellaert, Frank and Fallon, Maurice},
  journal={arXiv preprint arXiv:2610.14951},
  year={2026}
}