Projects
Jump to a specific research topic:
3D Reconstruction | Legged Robot Navigation | Forest Mapping | LiDAR Mapping
Recent Projects
3D Reconstruction
Legged Robot Navigation
Forest Mapping
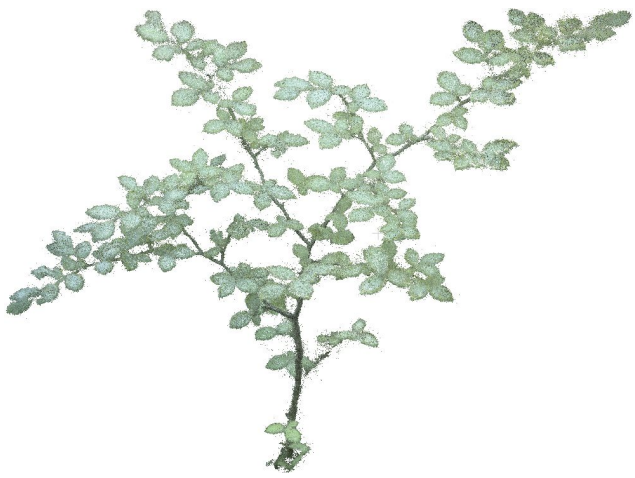
As part of the DigiForest project, we are working on new systems to autonomously build forest inventories with legged platforms, which we have deployed in the UK, Finland, and Switzerland
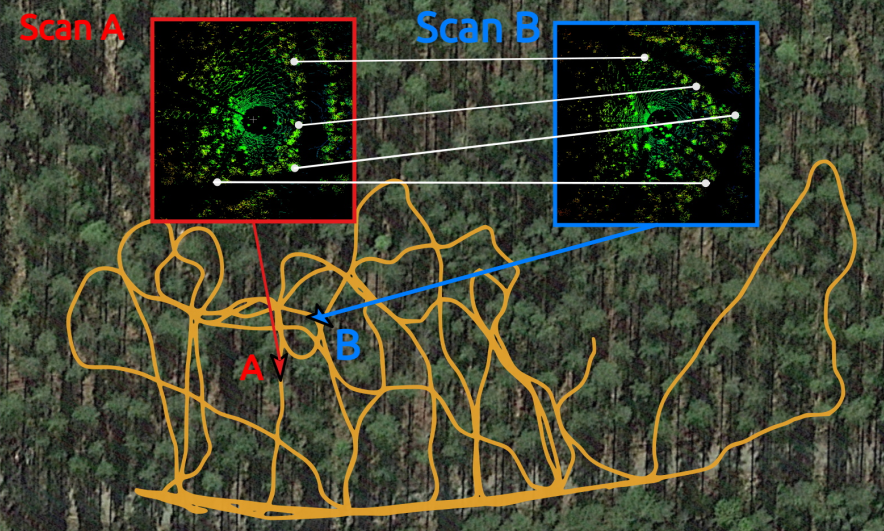
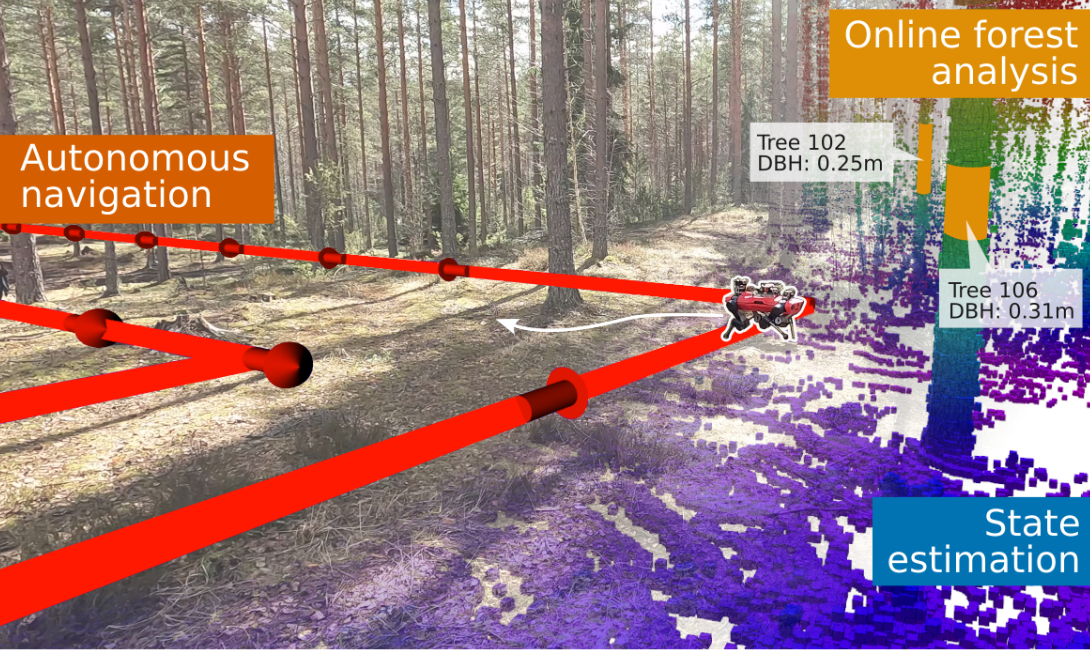
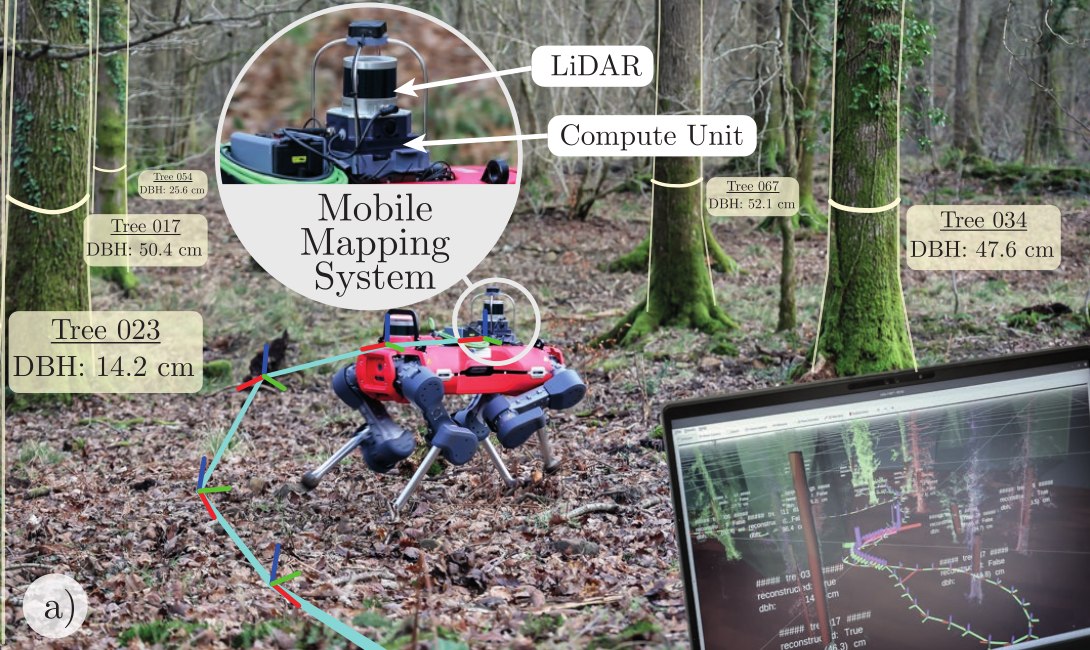
Markerless Aerial-Terrestrial Co-Registration of Forest Point Cloudsusing a Deformable Pose Graph. Benoit Casseau, Nived Chebrolu, Matias Mattamala, Leonard Freissmuth, Maurice Fallon, IEEE/RSJ Intl. Conf. on Intelligent Robots and Systems (IROS), 2024.
 Paper
LiDAR Mapping
Visual Navigation
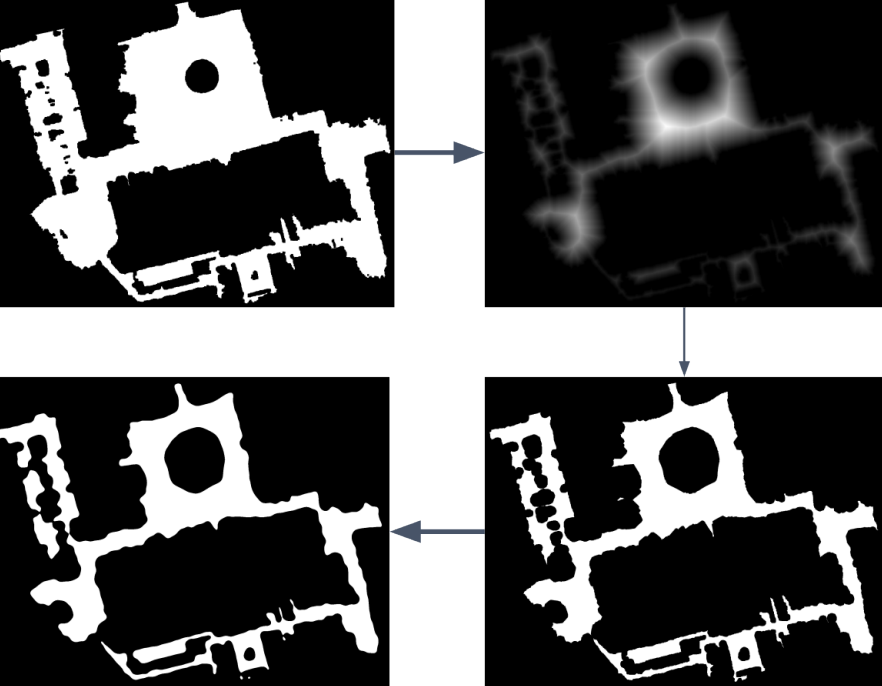
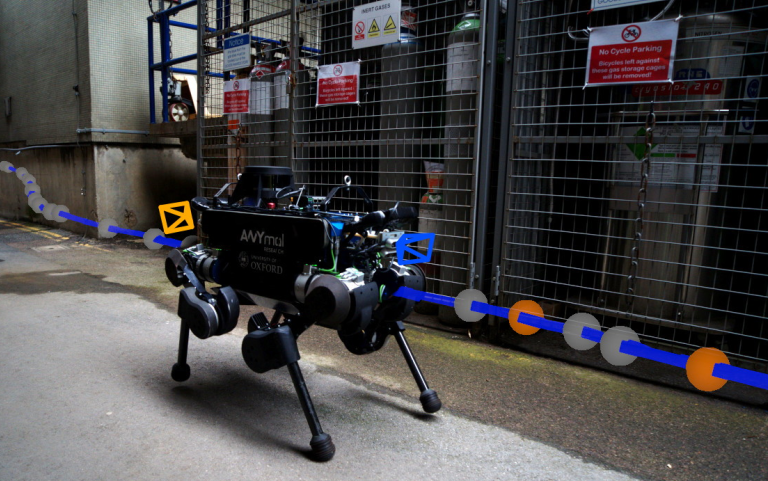
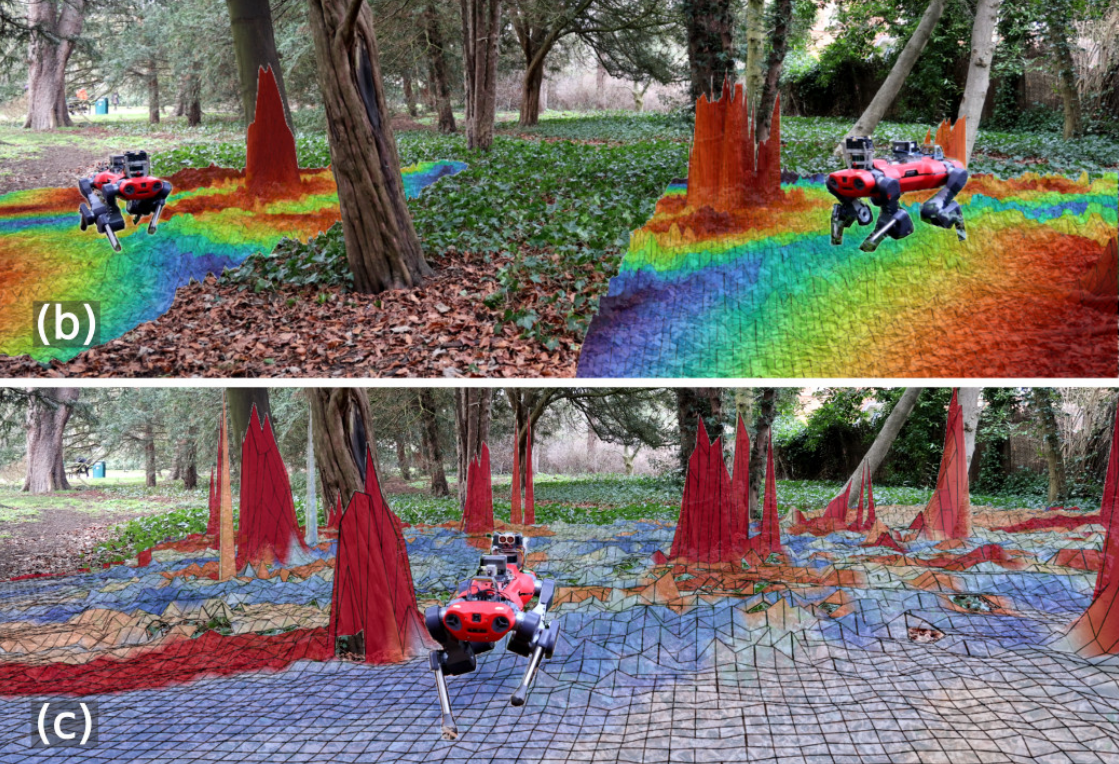
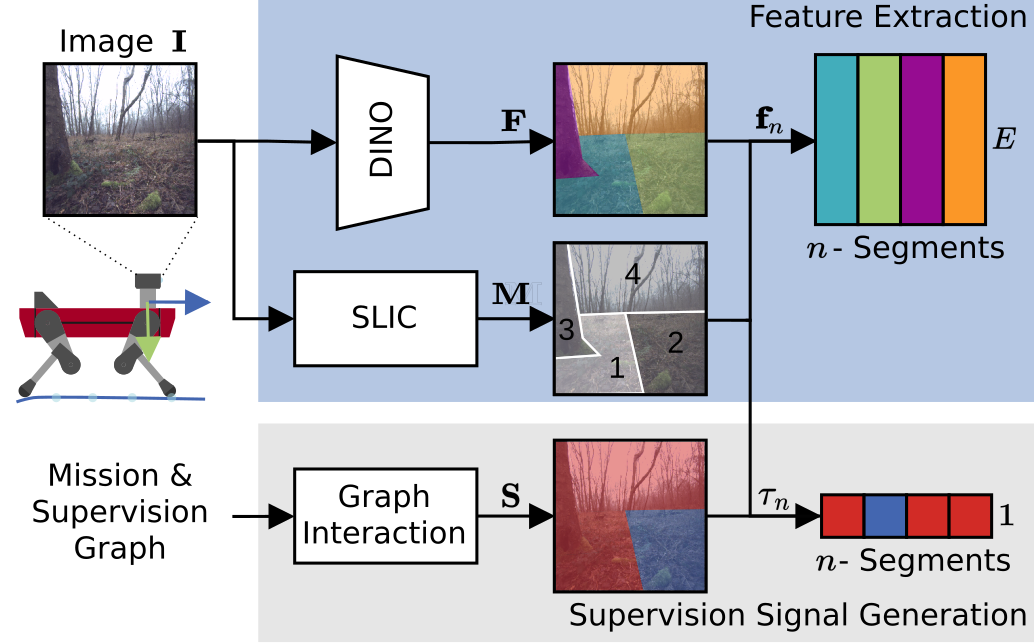
Wild Visual Navigation: Fast Traversability Learning via Pre-Trained Models and Online Self-Supervision. Matias Mattamala, Jonas Frey, Piotr Libera, Nived Chebrolu, Georg Martius, Cesar Cadena, Marco Hutter, Maurice Fallon, Autonomous Robots, 2025.
Paper
Underground Exploration
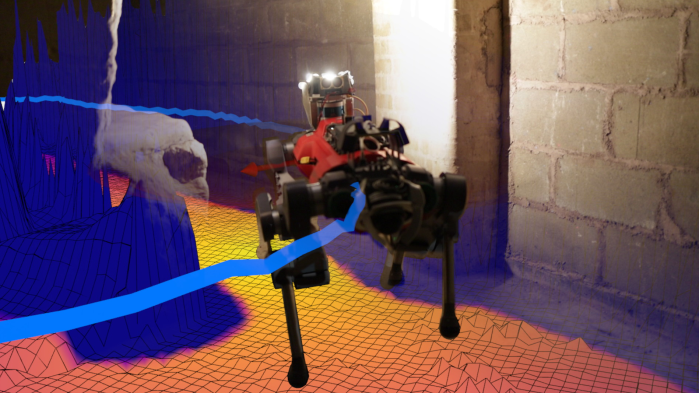
During 2018-2021 we were part of Team CERBERUS in the DARPA Subterranean (SubT) Challenge. This motivated research on state estimation, exploration, and safe navigation with quadruped robots in underground environments.
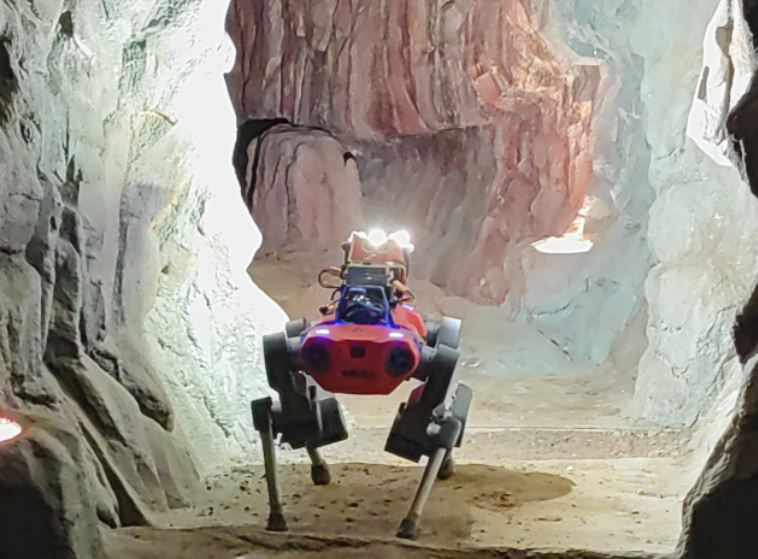
Team Cerberus wins the DARPA Subterranean Challenge: Technical overview and lessons learned. Marco Tranzatto, Mihir Dharmadhikari, Lukas Bernreiter, Marco Camurri, Shehryar Khattak, Frank Mascarich, Patrick Pfreundschuh, David Wisth, Samuel Zimmermann, Mihir Kulkarni, Victor Reijgwart, Benoit Casseau, Timon Homberger, Paolo Petris, Lionel Ott, Wayne Tubby, Gabriel Waibel, Huan Nguyen, Cesar Cadena, Russell Buchanan, Lorenz Wellhausen, Nikhil Khedekar, Olov Andersson, Lintong Zhang, Takahiro Miki, Tung Dang, Matias Mattamala, Markus Montenegro, Konrad Meyer, Xiangyu Wu, Adrien Briod, Mark Mueller, Maurice Fallon, Roland Siegwart, Marco Hutter, Kostas Alexis, Field Robotics Journal, 2022.
Paper  Video
 Webpage
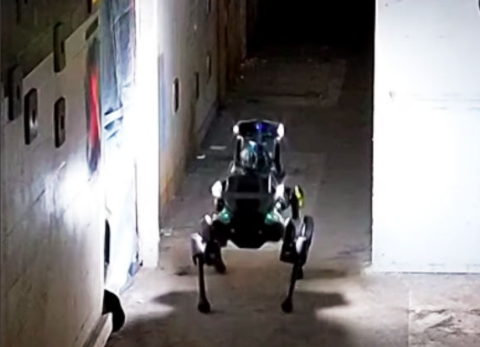
CERBERUS: Autonomous Legged and Aerial Robotic Exploration in the Tunnel and Urban Circuits of the DARPA Subterranean Challenge. Marco Tranzatto, Frank Mascarich, Lukas Bernreiter, Carolina Godinho, Marco Camurri, Shehryar Khattak, Tung Dang, Victor Reijgwart, Johannes Loeje, David Wisth, Samuel Zimmermann, Huan Nguyen, Marius Fehr, Lukas Solanka, Russell Buchanan, Marko Bjelonic, Nikhil Khedekar, Mathieu Valceschini, Fabian Jenelten, Mihir Dharmadhikari, Timon Homberger, Paolo Petris, Lorenz Wellhausen, Mihir Kulkarni, Takahiro Miki, Satchel Hirsch, Markus Montenegro, Christos Papachristos, Fabian Tresoldi, Jan Carius, Giorgio Valsecchi, Joonho Lee, Konrad Meyer, Xiangyu Wu, Juan Nieto, Andy Smith, Marco Hutter, Roland Siegwart, Mark Mueller, Maurice Fallon, Kostas Alexis, Field Robotics Journal, 2022.
Paper Video Webpage
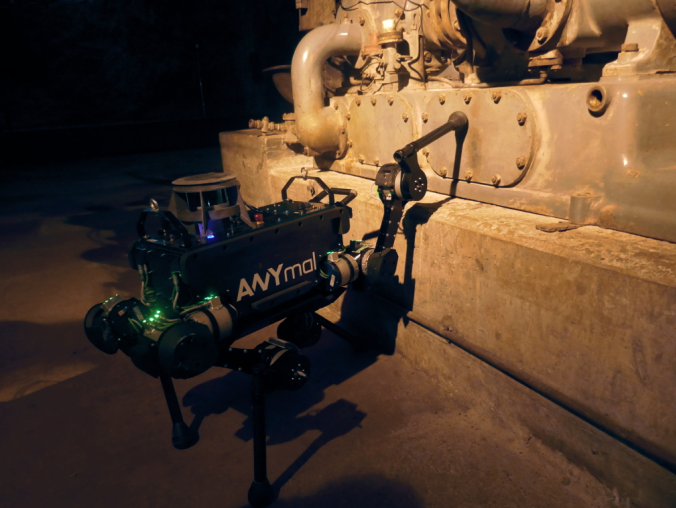
Industrial Inspection
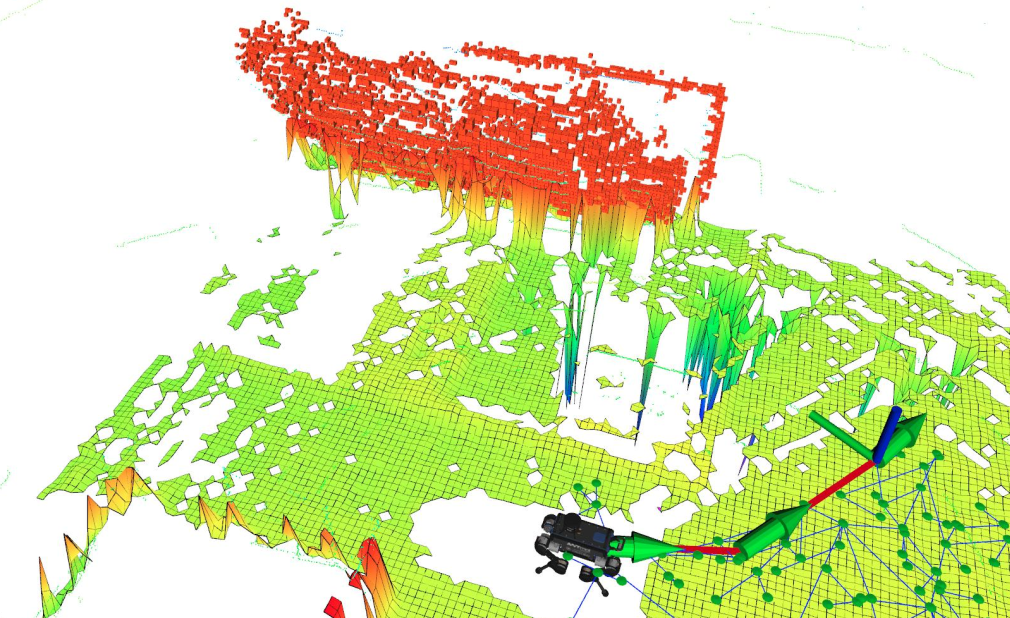
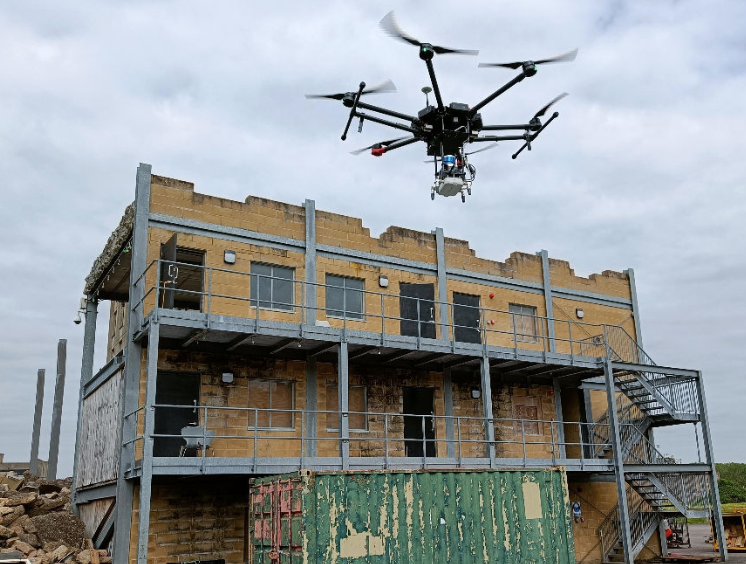
As part of our contributions within the ORCA Project (2017-2022), we developed vision- and LiDAR-based navigation systems for legged platforms in industrial facilities.
Misc Projects
- OASIS-Map: Object-Level Change Detection in Multi-Session Mapping using Semantic Correspondence Matching
- ScaRF-SLAM: Scale-Consistent Reconstruction with Feed-Forward Models and Classical Visual SLAM
- LEXI-SG: Monocular 3D Scene Graph Mapping with Room-Guided Feed-Forward Reconstruction
- Language-EXtended Indoor SLAM (LEXIS)
- Exosense: A vision system For exoskeletons
- 3D Reconstruction with Ultrasound and Vision
- InstaLoc: Lidar Localisation through Instance Segmentation
- Frontier Mapping Payload
- Depth Completion
- VILENS Tightly Fused Multi-Sensor Odometry
- Lidar Simultaneous Localization and Mapping
- Lidar Place Recognition
- Active Mapping
- Online Planning of Adaptive Locomotion
Collaborative Projects
DRS has been project partners in a variety of collaborative research projects with partners from across the UK, Europe as well as the US, Korea and other places.
Some specific collaborative projects include:
- Digiforest - Digital Analytics and Robotics for Sustainable Forestry
- MEMMO - Memory of Motion
- THING - subTerranean Haptic INvestiGator
- EPSRC ORCA Research Hub
- EPSRC RAIN Research Hub
- DARPA SubT Challenge
Collaborators in these projects included Seoul National University (Kim), Sogang University, KEIT, MIT (Carlone), ETH Zurich (Cadena, Leutenegger, Hutter), Bonn (Stachniss), NTNU (Alexis), LAAS Toulouse (Gepetto Group), Edinburgh (Vijayakumar), University of Manchester (Lennox, Watson) and Heriot Watt University.