Publications
Jump to an individual year:
2026
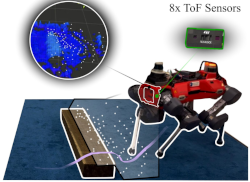
Quadruped Obstacle Avoidance and Footstep Planning with Distributed Low-cost Time-of-Flight Sensors. Giammarco Caroleo, Timothée Mahamoodally, Matteo Manzardo, Jin Jin, Marco Pontin, Matias Mattamala, Renato Vidoni, Perla Maiolino, Maurice Fallon, IEEE Robotics and Automation Letters (RAL), 2026.
 Paper
 Video
 Webpage
2025
SafeMove: Multi-Model Navigation for Fail-Resistant Autonomous Nuclear Material Transport. David Marquez-Gamez, Matt Harrison, Christian Pilon, Robert Marwood, Samuel Stephens, Michal Staniaszek, Tobit Flatscher, Chris Prahacs, Nick Hawes, Maurice Fallon, Waste Management Conference, 2025.
Paper
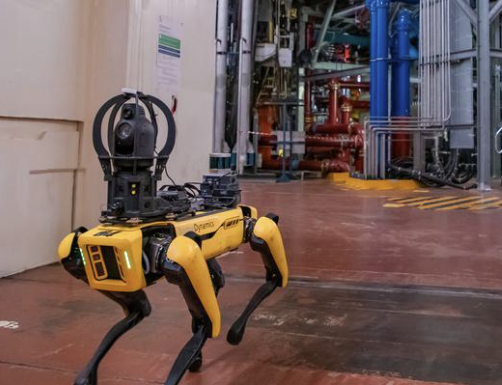
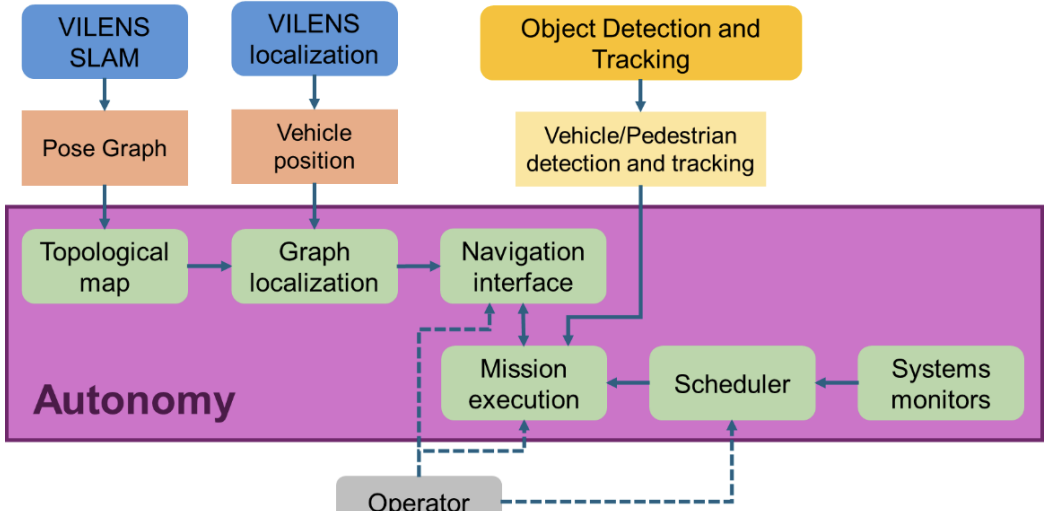
AutoInspect: Toward Long-Term Autonomous Inspection and Monitoring. Michal Staniaszek, Tobit Flatscher, Joseph Rowell, Hanlin Niu, Wenxing Liu, Yang You, Matthew Gadd, Matias Mattamala, Alex Schutz, Daniele Martini, Luke Pitt, Robert Skilton, Maurice Fallon, Nick Hawes, IEEE Transactions on Field Robotics, 2025.
Paper
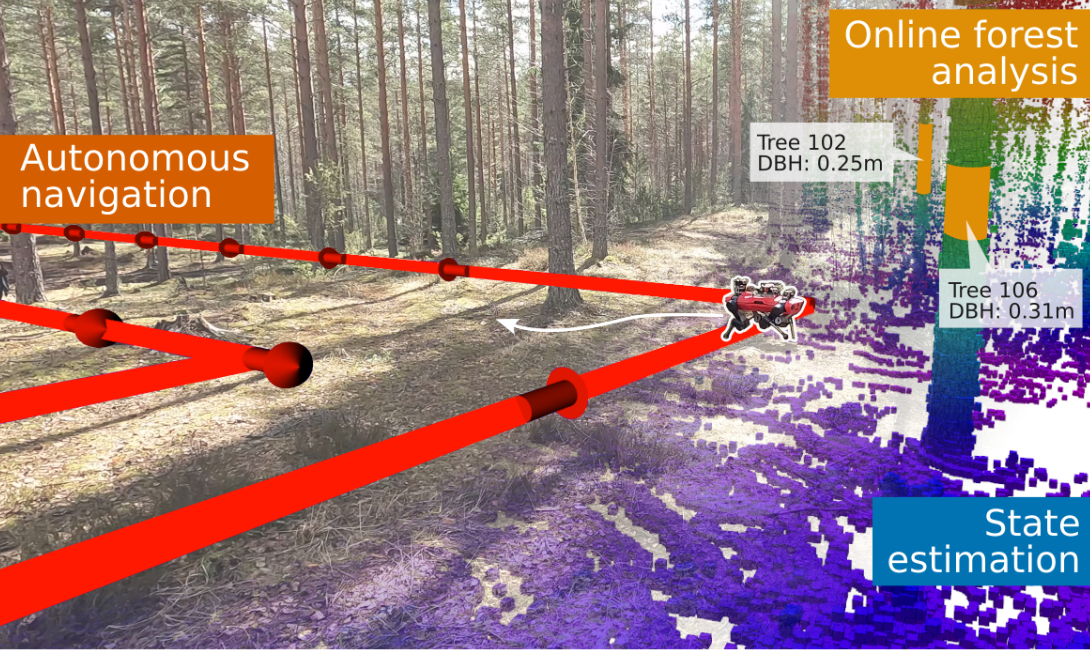
DigiForest: Digital Analytics and Robotics for Sustainable Forestry. Marco Camurri, Enrico Tomelleri, Matias Mattamala, Sebastian Laina, Martin Jacquet, Jens Behley, Sunni Kushwaha, Fang Nan, Nived Chebrolu, Leonard Freißmuth, Marvin Harms, Meher Malladi, Fan Yang, Jonas Frey, Cesar Cadena, Marco Hutter, Janine Schweier, Kostas Alexis, Cyrill Stachniss, Maurice Fallon, Stefan Leutenegger, Recent Advances in Robotic Perception for Forestry, 2025.
Paper
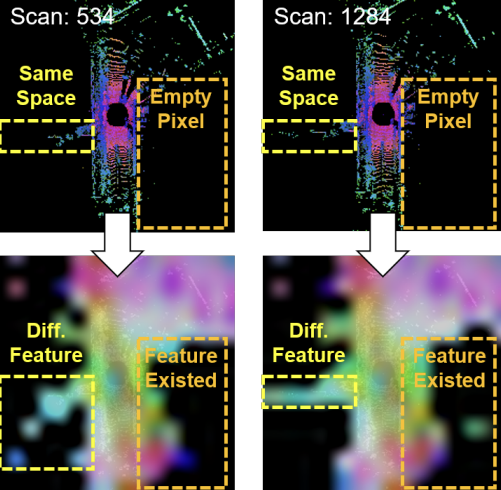
LiDAR SLAM. Jens Behley, Maurice Fallon, Shibo Zhao, Giseop Kim, Ji Zhang, Fu Zhang, Ayoung Kim, The SLAM Handbook: From Localization and Mapping to Spatial Intelligence, 2025.
Paper
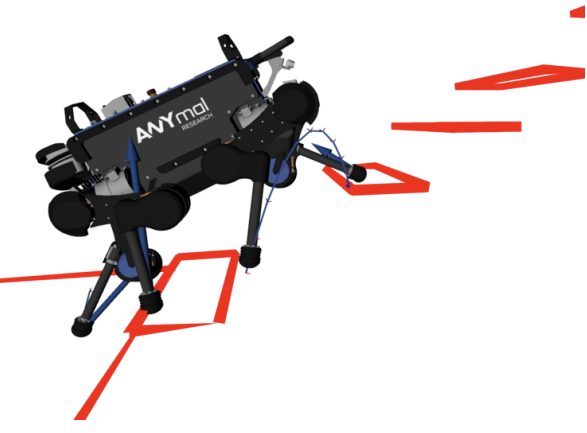
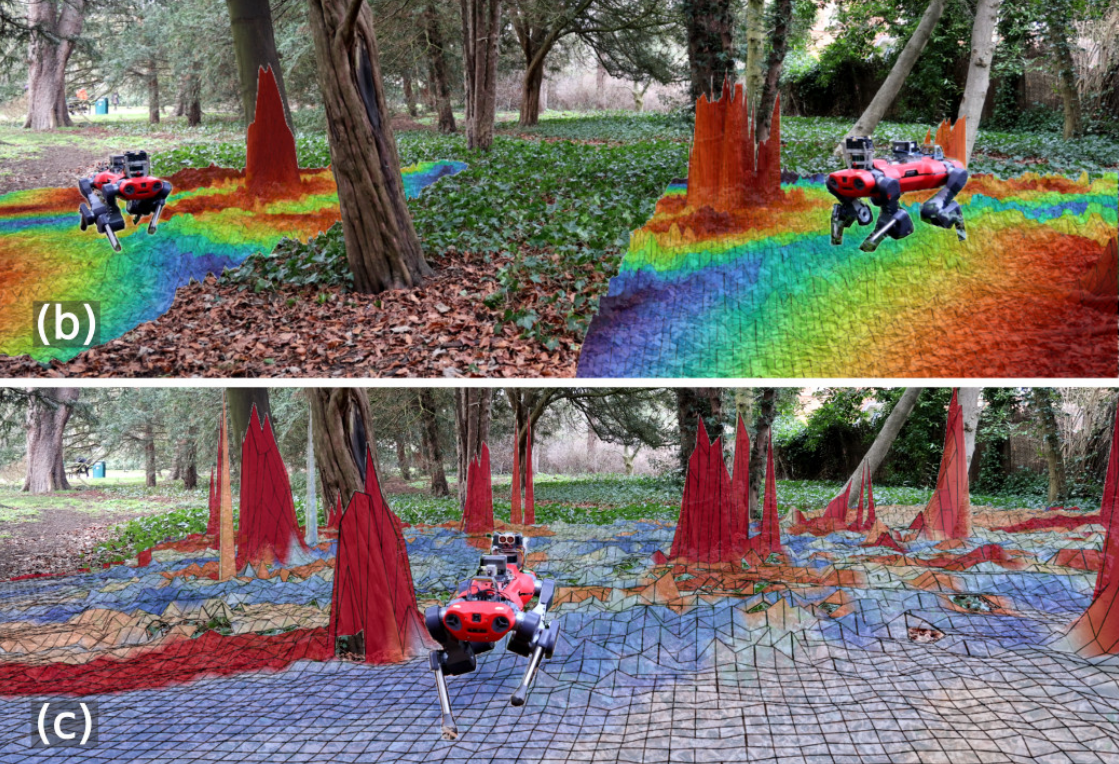
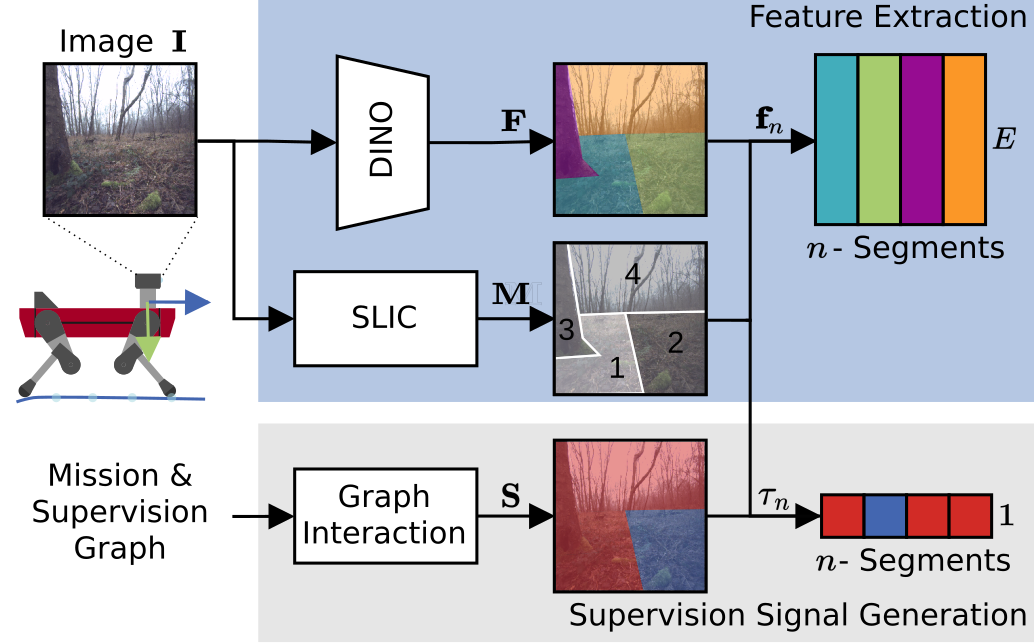
Wild Visual Navigation: Fast Traversability Learning via Pre-Trained Models and Online Self-Supervision. Matias Mattamala, Jonas Frey, Piotr Libera, Nived Chebrolu, Georg Martius, Cesar Cadena, Marco Hutter, Maurice Fallon, Autonomous Robots, 2025.
Paper
2024
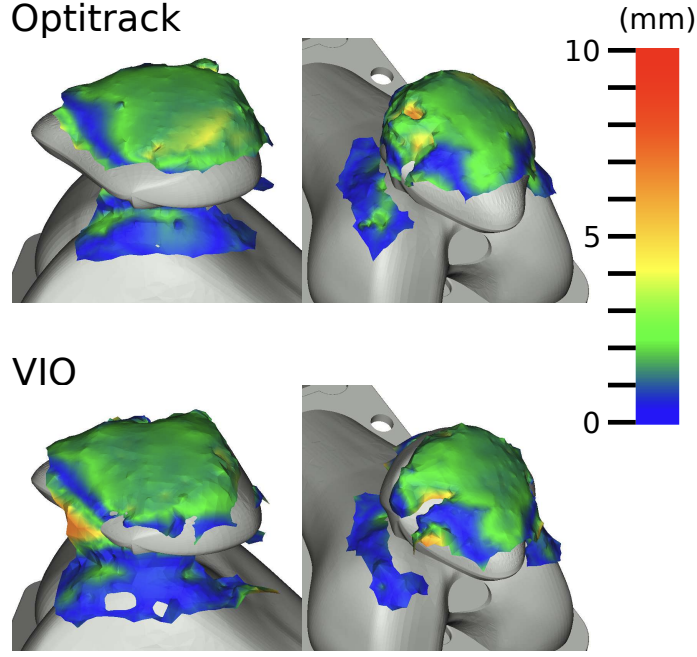
3D Bone Surface Image Reconstruction from Freehand Ultrasound using Visual-Inertial Odometry and Deep Inertial Odometry. Russell Buchanan, S. Tu, Marco Camurri, Stephen Mellon, Maurice Fallon, IEEE Symposium on Medical Measurements and Applications, 2024.
Paper
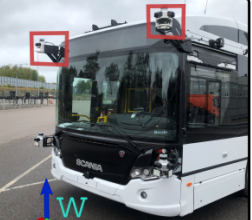
IMU-based Online Multi-lidar Calibration. Sandipan Das, Bengt Boberg, Maurice Fallon, Saikat Chatterjee, IEEE Intelligent Vehicles Symposium, 2024.
Paper
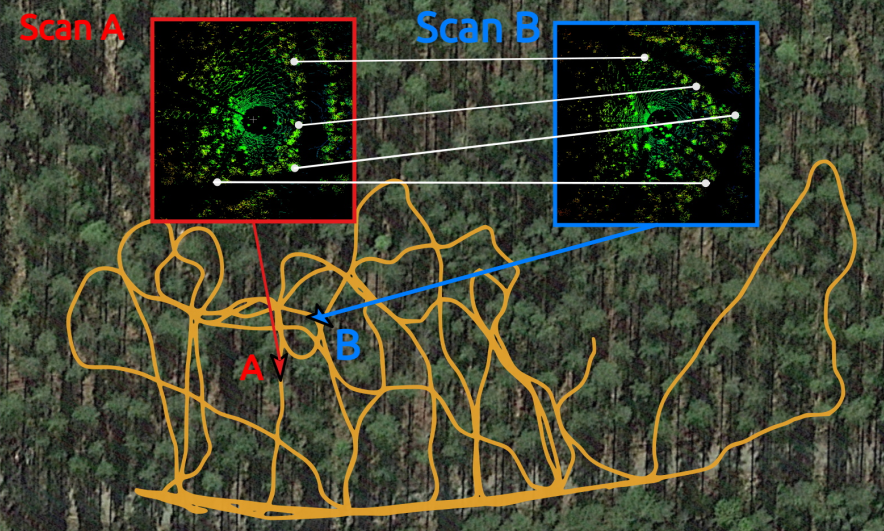
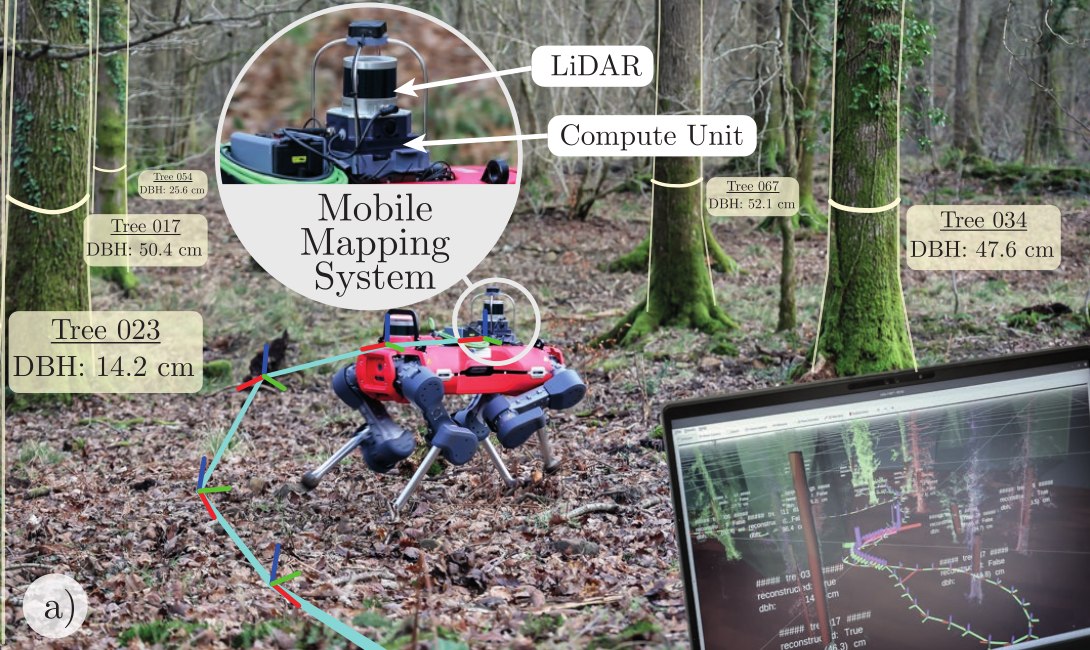
Markerless Aerial-Terrestrial Co-Registration of Forest Point Cloudsusing a Deformable Pose Graph. Benoit Casseau, Nived Chebrolu, Matias Mattamala, Leonard Freissmuth, Maurice Fallon, IEEE/RSJ Intl. Conf. on Intelligent Robots and Systems (IROS), 2024.
Paper
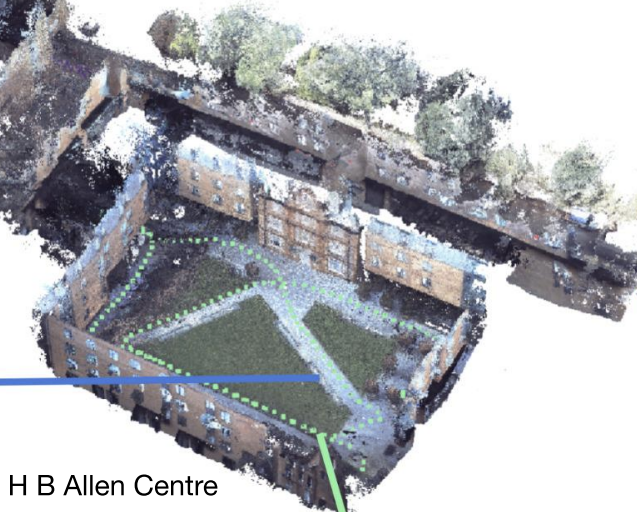
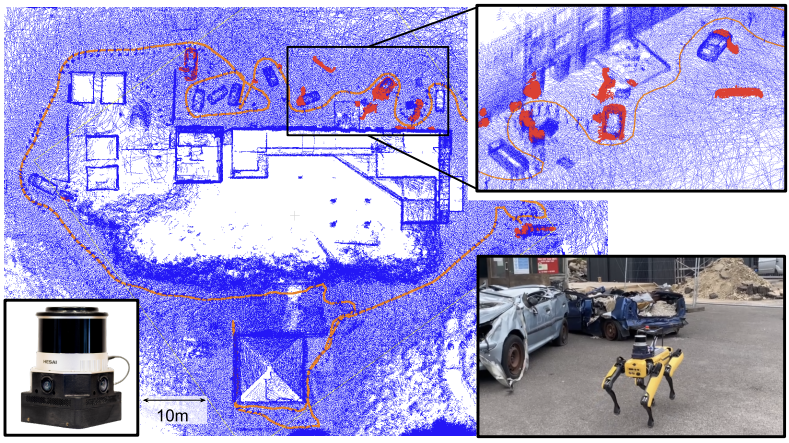
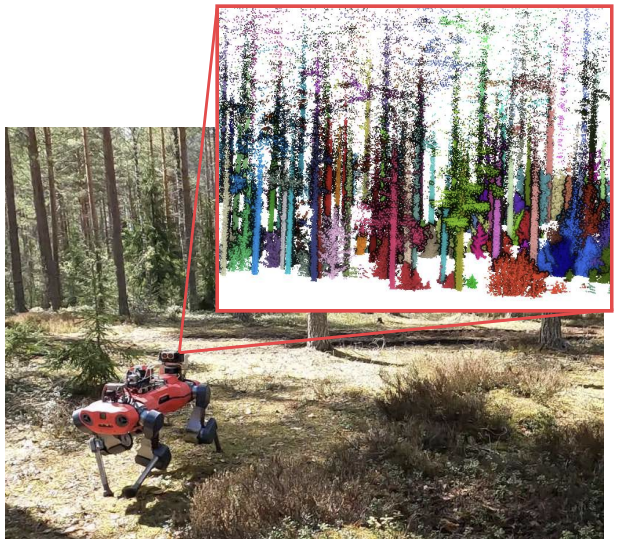
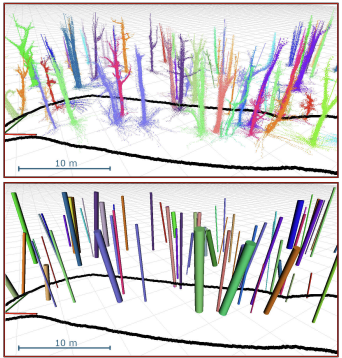
Tree Instance Segmentation and Traits Estimation for Forestry Environments Exploiting LiDAR Data Collected by Mobile Robots. Meher Malladi, Tiziano Guadagnino, Luca Lobefaro, Matias Mattamala, Holger Griess, Janine Schweier, Nived Chebrolu, Maurice Fallon, Jens Behley, Cyrill Stachniss, IEEE Intl. Conf. on Robotics and Automation (ICRA), 2024.
Paper Webpage
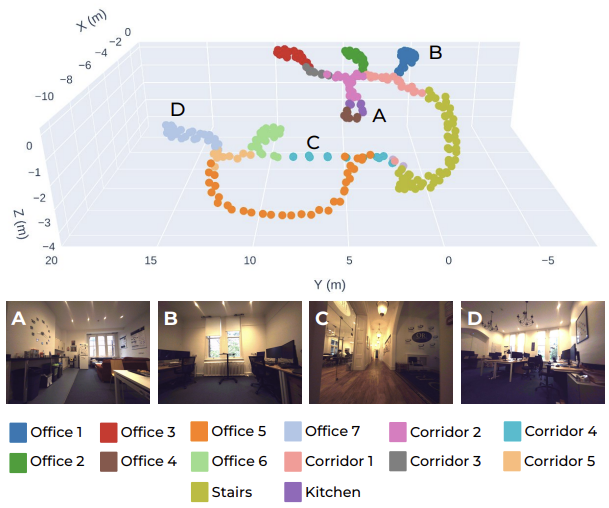
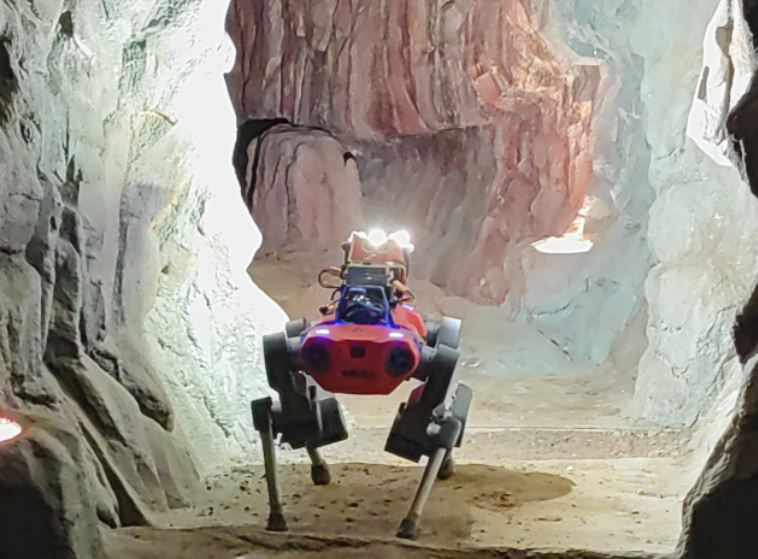
Team Cerberus wins the DARPA Subterranean Challenge: Technical overview and lessons learned. Marco Tranzatto, Mihir Dharmadhikari, Lukas Bernreiter, Marco Camurri, Shehryar Khattak, Frank Mascarich, Patrick Pfreundschuh, David Wisth, Samuel Zimmermann, Mihir Kulkarni, Victor Reijgwart, Benoit Casseau, Timon Homberger, Paolo Petris, Lionel Ott, Wayne Tubby, Gabriel Waibel, Huan Nguyen, Cesar Cadena, Russell Buchanan, Lorenz Wellhausen, Nikhil Khedekar, Olov Andersson, Lintong Zhang, Takahiro Miki, Tung Dang, Matias Mattamala, Markus Montenegro, Konrad Meyer, Xiangyu Wu, Adrien Briod, Mark Mueller, Maurice Fallon, Roland Siegwart, Marco Hutter, Kostas Alexis, Field Robotics Journal, 2024.
Paper Video Webpage
2023
2022
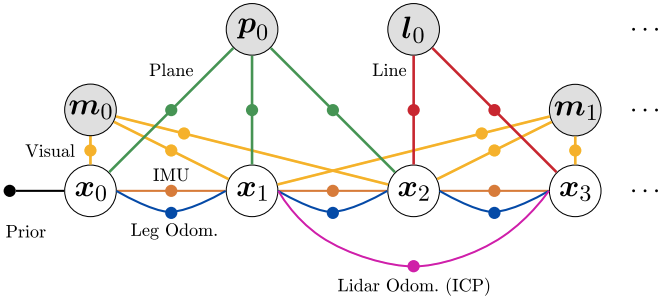
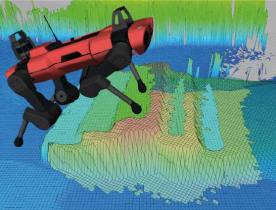
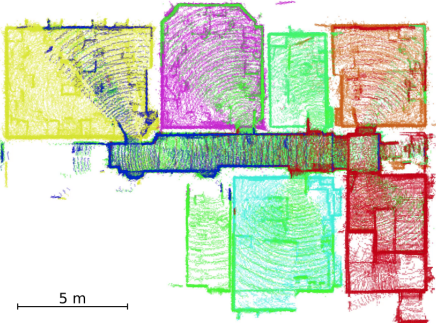
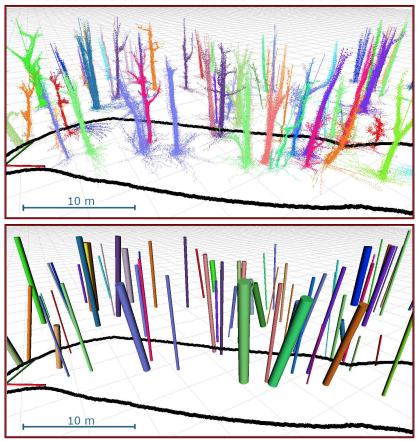
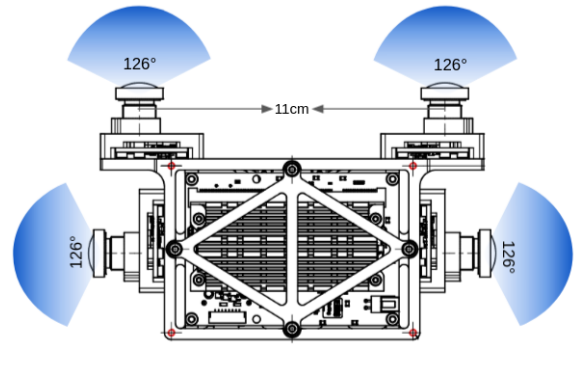
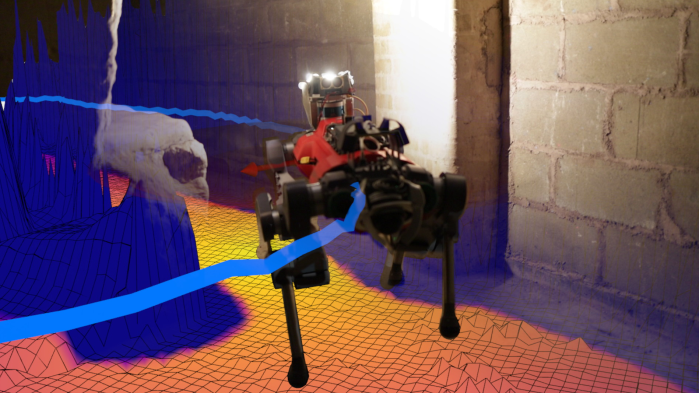
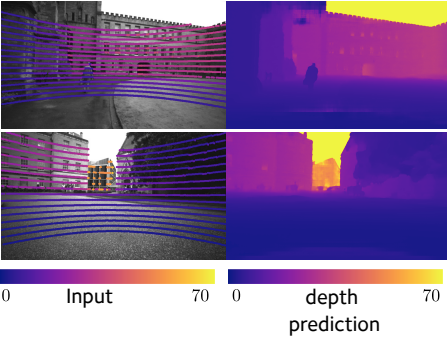
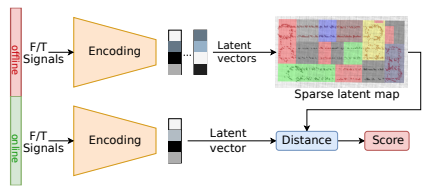
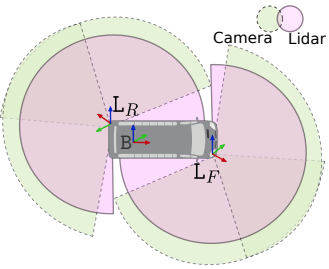
Extrinsic Calibration and Verification of Multiple Non-overlapping Field of View Lidar Sensors. Sandipan Das, Navid Mahabadi, Addi Djikic, Cesar Nassir, Saikat Chatterjee, Maurice Fallon, IEEE Intl. Conf. on Robotics and Automation (ICRA), 2022.
Paper
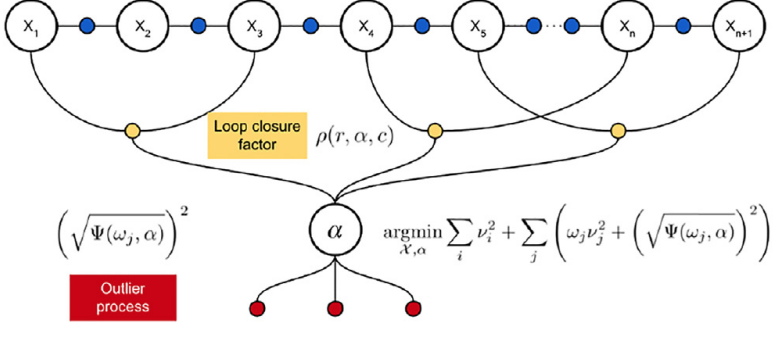
AEROS: AdaptivE RObust Least-Squares for Graph-Based SLAM. Milad Ramezani, Matias Mattamala, Maurice Fallon, Frontiers in Robotics and AI, 2022.
Paper
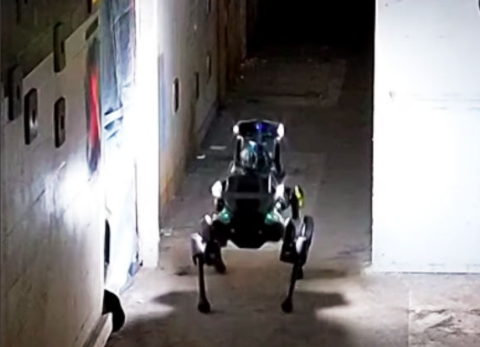
CERBERUS: Autonomous Legged and Aerial Robotic Exploration in the Tunnel and Urban Circuits of the DARPA Subterranean Challenge. Marco Tranzatto, Frank Mascarich, Lukas Bernreiter, Carolina Godinho, Marco Camurri, Shehryar Khattak, Tung Dang, Victor Reijgwart, Johannes Loeje, David Wisth, Samuel Zimmermann, Huan Nguyen, Marius Fehr, Lukas Solanka, Russell Buchanan, Marko Bjelonic, Nikhil Khedekar, Mathieu Valceschini, Fabian Jenelten, Mihir Dharmadhikari, Timon Homberger, Paolo Petris, Lorenz Wellhausen, Mihir Kulkarni, Takahiro Miki, Satchel Hirsch, Markus Montenegro, Christos Papachristos, Fabian Tresoldi, Jan Carius, Giorgio Valsecchi, Joonho Lee, Konrad Meyer, Xiangyu Wu, Juan Nieto, Andy Smith, Marco Hutter, Roland Siegwart, Mark Mueller, Maurice Fallon, Kostas Alexis, Field Robotics Journal, 2022.
Paper Video Webpage
2021
2020
Legged Robots For Autonomous Inspection And Monitoring Of Offshore Assets. Milad Ramezani, Martim Brandao, Benoit Casseau, Ioannis Havoutis, Maurice Fallon, Offshore Technology Conference, 2020.
 DOI
2019
2018
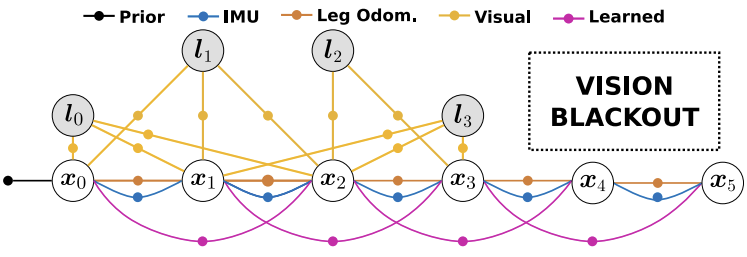
Accurate and robust localization for walking robots fusing kinematics, inertial, vision and LIDAR. Maurice Fallon, Interface Focus, 2018.
Paper
Director: A User Interface Designed for Robot Operation With Shared Autonomy. Pat Marion, Maurice Fallon, Robin Deits, Andres Valenzuela, Claudia D’Arpino, Greg Izatt, Lucas Manuelli, Matt Antone, Hongkai Dai, Twan Koolen, John Carter, Scott Kuindersma, Russ Tedrake, The DARPA Robotics Challenge Finals: Humanoid Robots To The Rescue, 2018.
Paper Webpage DOI
2017
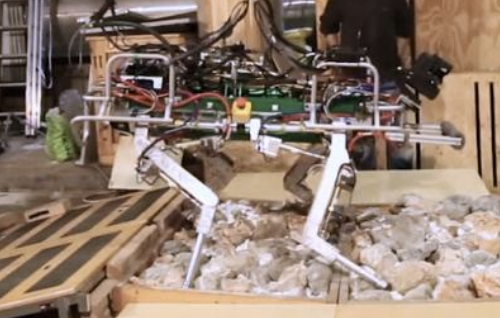
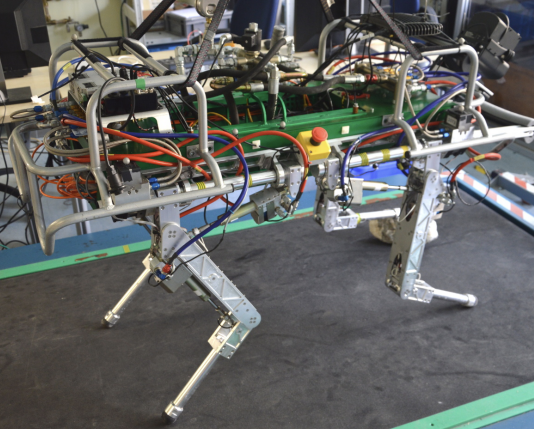
Probabilistic Contact Estimation and Impact Detection for State Estimation of Quadruped Robots. Marco Camurri, Maurice Fallon, Stephane Bazeille, Andreea Radulescu, Victor Barasuol, Darwin Caldwell, Claudio Semini, IEEE Robotics and Automation Letters, 2017.
Paper
Director: A User Interface Designed for Robot Operation With Shared Autonomy. Pat Marion, Maurice Fallon, Robin Deits, Andres Valenzuela, Claudia D’Arpino, Greg Izatt, Lucas Manuelli, Matt Antone, Hongkai Dai, Twan Koolen, John Carter, Scott Kuindersma, Russ Tedrake, J. of Field Robotics, 2017.
Paper
2016
Sensor fusion and State estimation of the robot. Francesco Nori, Silvio Traversaro, Maurice Fallon, Humanoid Robotics: a Reference, 2016.
Paper
2015
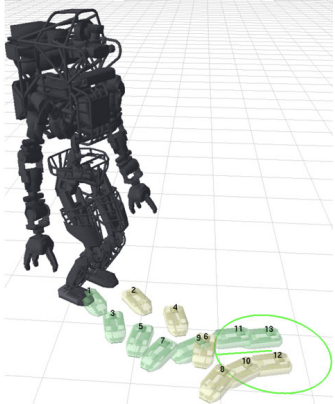
An Architecture for Online Affordance-based Perception and Whole-body Planning. Maurice Fallon, Scott Kuindersma, Sisir Karumanchi, Matthew Antone, Toby Schneider, Hongkai Dai, Claudia D’Arpino, Robin Deits, Matt DiCicco, Dehann Fourie, Twan Koolen, Pat Marion, Michael Posa, Andres Valenzuela, Kuan-Ting Yu, Julie Shah, Karl Iagnemma, Russ Tedrake, Seth Teller, J. of Field Robotics, 2015.
Paper
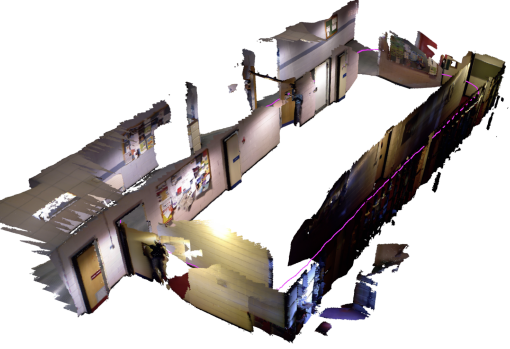
Real-time Large Scale Dense RGB-D SLAM with Volumetric Fusion. Thomas Whelan, Michael Kaess, Hordur Johannsson, Maurice Fallon, John Leonard, John McDonald, Intl. J. of Robotics Research, 2015.
Paper
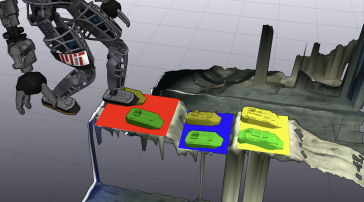
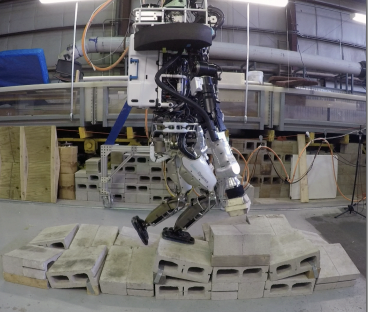
Optimization-based locomotion planning, estimation, and control design for the Atlas humanoid robot. Scott Kuindersma, Robin Deits, Maurice Fallon, Andres Valenzuela, Hongkai Dai, Frank Permenter, Twan Koolen, Pat Marion, Russ Tedrake, Autonomous Robots, 2015.
Paper
2014
3D mapping, localisation and object retrieval using low cost robotic platforms: A robotic search engine for the real-world. Thomas Whelan, Michael Kaess, Ross Finman, Maurice Fallon, Hordur Johannsson, John Leonard, John McDonald, RSS Workshop on RGB-D: Advanced Reasoning with Depth Cameras, 2014.
Paper
A Summary of Team MIT’s Approach to the Virtual Robotics Challenge. R. Tedrake, M. Fallon, S. Karumanchi, S. Kuindersma, M. Antone, T. Schneider, T. Howard, M. Walter, H. Dai, R. Deits, M. Fleder, D. Fourie, R. Hammoud, S. Hemachandra, P. Ilardi, C. Perez-D’Arpino, S. Pillai, A. Valenzuela, C. Cantu, C. Dolan, I. Evans, S. Jorgensen, J. Kristeller, J. Shah, K. Iagnemma, S. Teller, IEEE Intl. Conf. on Robotics and Automation (ICRA), 2014.
Paper Video
Drift-Free Humanoid State Estimation fusing Kinematic, Inertial and LIDAR sensing. Maurice Fallon, Matthew Antone, Nicholas Roy, Seth Teller, IEEE/RSJ Int. Conf. on Humanoid Robots, 2014.
Paper
Mapping Complex Marine Environments with Autonomous Surface Craft. Jacques Leedekerken, Maurice Fallon, John Leonard, Experimental Robotics, 2014.
Paper
2013
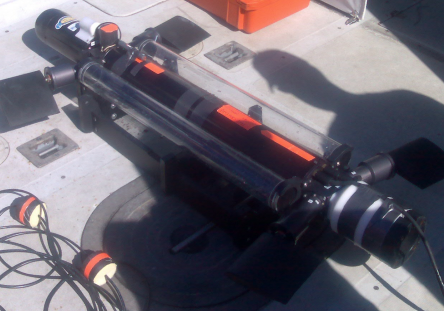
Relocating Underwater Features Autonomously Using Sonar-Based SLAM. Maurice Fallon, John Folkesson, Hunter McClelland, John Leonard, Journal of Oceanic Engineering, 2013.
Paper
The MIT Stata Center Dataset. Maurice Fallon, Hordur Johannsson, Michael Kaess, John Leonard, Intl. J. of Robotics Research, IJRR, 2013.
Paper
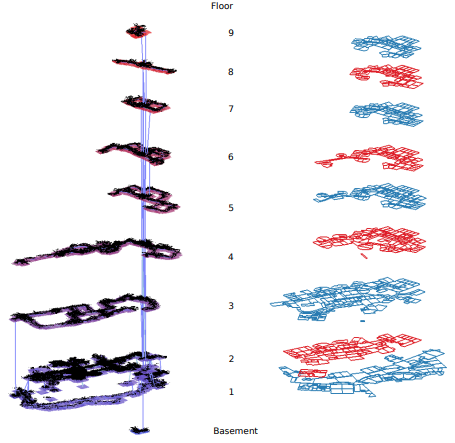
Temporally Scalable Visual SLAM using a Reduced Pose Graph. Hordur Johannsson, Michael Kaess, Maurice Fallon, John Leonard, IEEE Intl. Conf. on Robotics and Automation (ICRA), 2013.
Paper
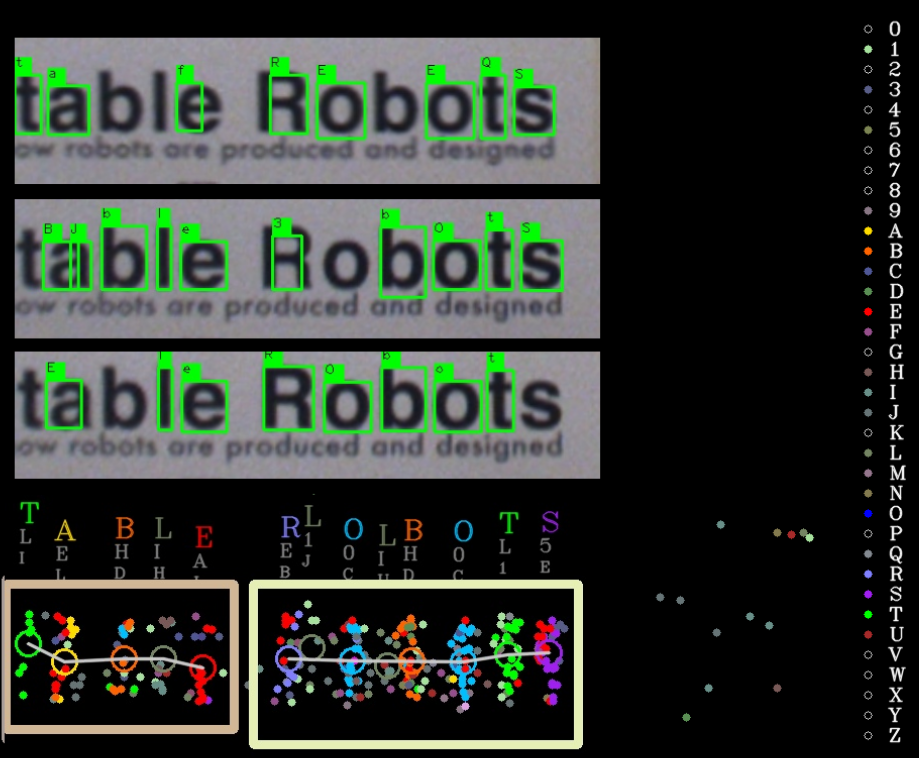
Spatially Prioritized and Persistent Text Detection and Decoding. Hsueh-Cheng Wang, Yafim Landa, Maurice Fallon, Seth Teller, International Workshop on Camera-Based Document Analysis and Recognition (CBDAR), 2013.
Paper
2012
Simultaneous Localization and Mapping in Marine Environments. Maurice Fallon, Hordur Johannsson, Michael Kaess, John Folkesson, Hunter McClelland, Brendan Englot, Franz Hover, John Leonard, Marine Robot Autonomy, 2012.
Paper
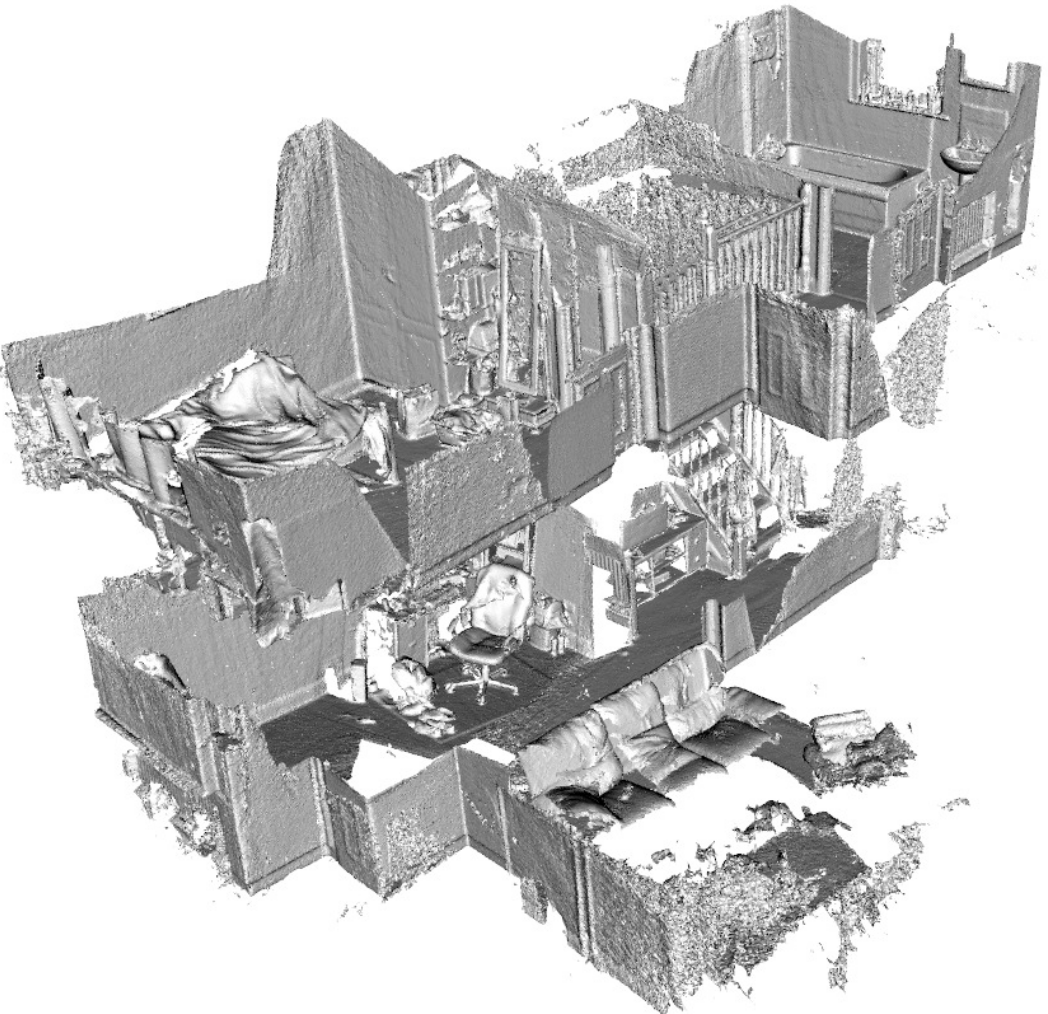
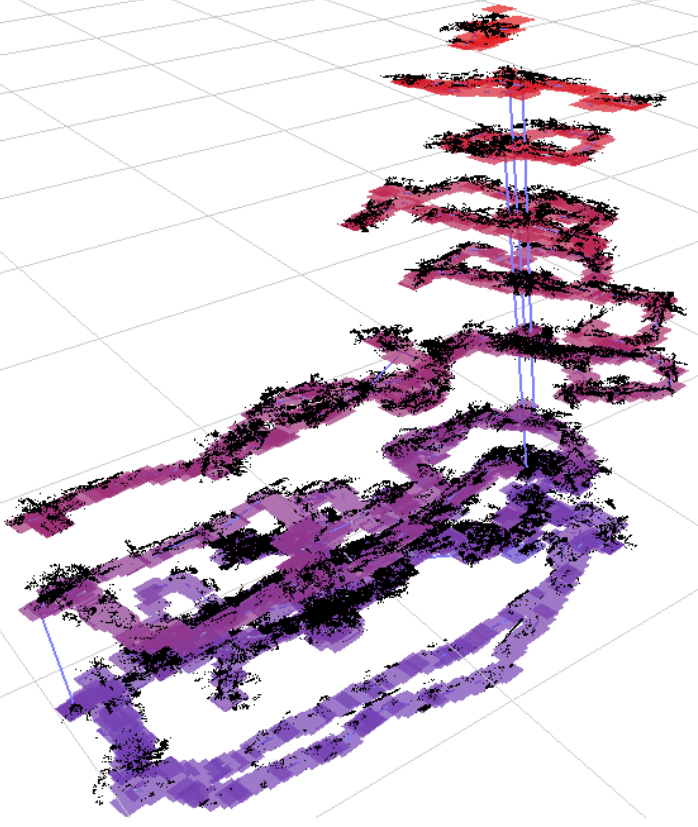
Temporally Scalable Visual SLAM using a Reduced Pose Graph. Hordur Johannsson, Michael Kaess, Maurice Fallon, John Leonard, CSAIL, MIT, 2012.
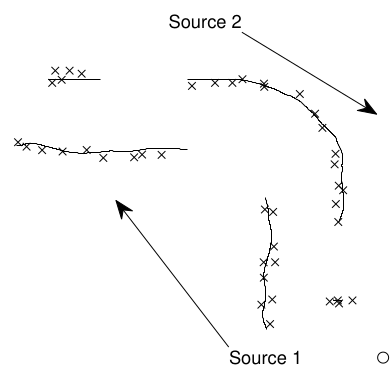
Acoustic Source Localisation and Tracking of a Time-Varying Number of Speakers. Maurice Fallon, Simon Godsill, IEEE Trans. on Audio, Speech, and Language Processing, 2012.
Paper
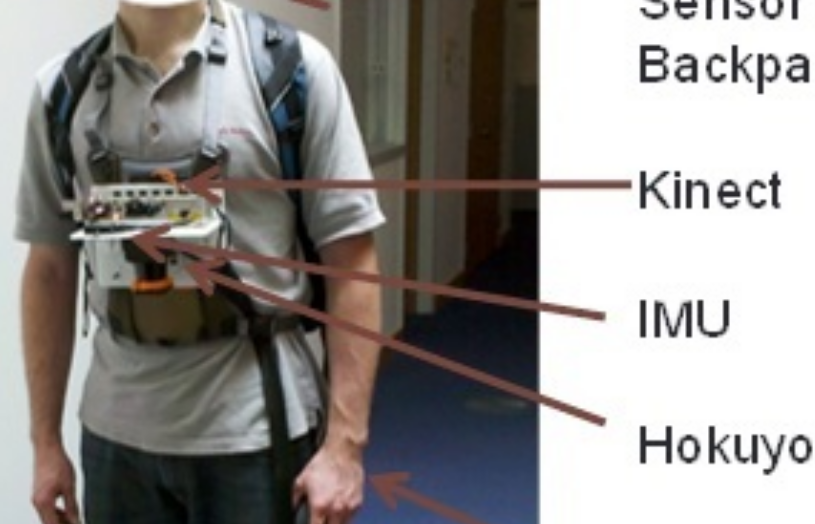
Sensor Fusion for Flexible Human-Portable Building-Scale Mapping. Maurice Fallon, Hordur Johannsson, Jonathon Brookshire, Seth Teller, John Leonard, IEEE/RSJ Intl. Conf. on Intelligent Robots and Systems (IROS), 2012.
Paper
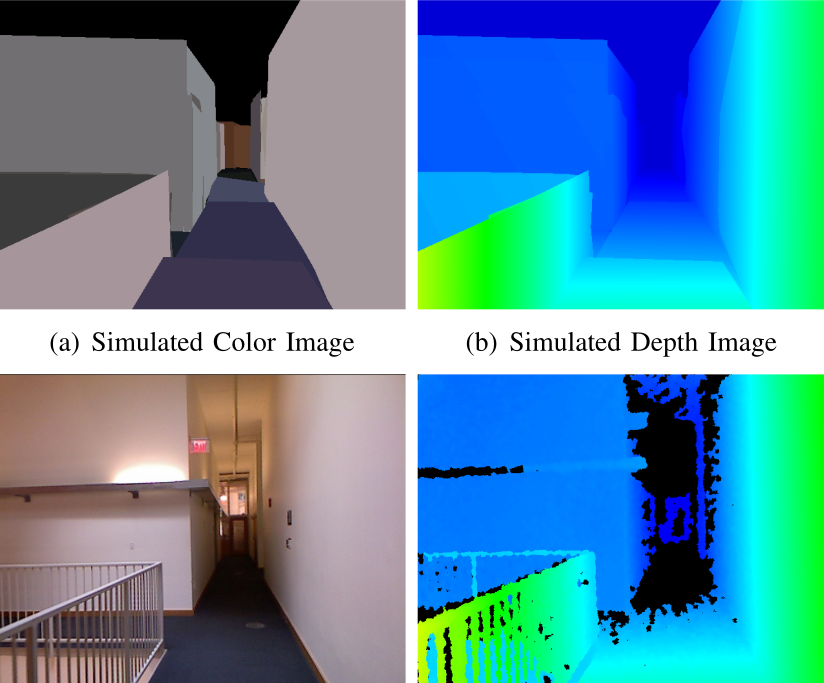
Efficient Scene Simulation for Robust Monte Carlo Localization using an RGB-D Camera. Maurice Fallon, Hordur Johannsson, John Leonard, IEEE Intl. Conf. on Robotics and Automation (ICRA), 2012.
Paper
2011
2010
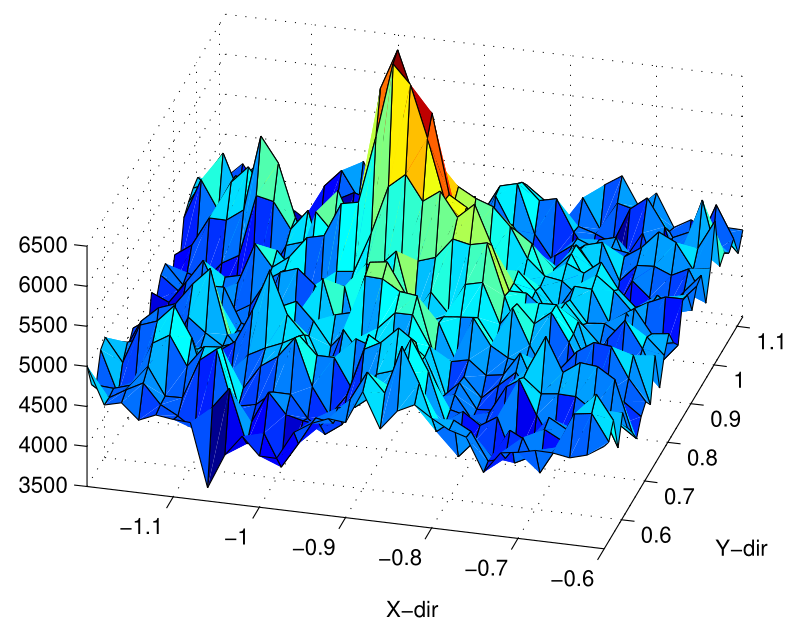
Acoustic Source Localisation and Tracking using Track Before Detect. Maurice Fallon, Simon Godsill, IEEE Trans. on Audio, Speech, and Language Processing, 2010.
Paper
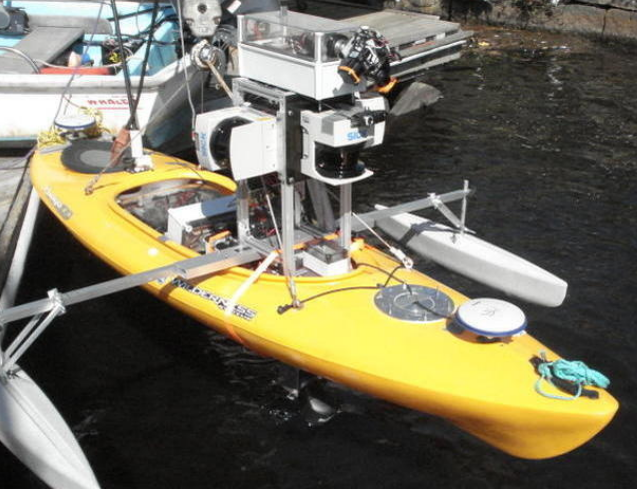
Mapping Complex Marine Environments with Autonomous Surface Craft. Jacques Leedekerken, Maurice Fallon, John Leonard, Intl. Sym. on Experimental Robotics (ISER), 2010.
Paper
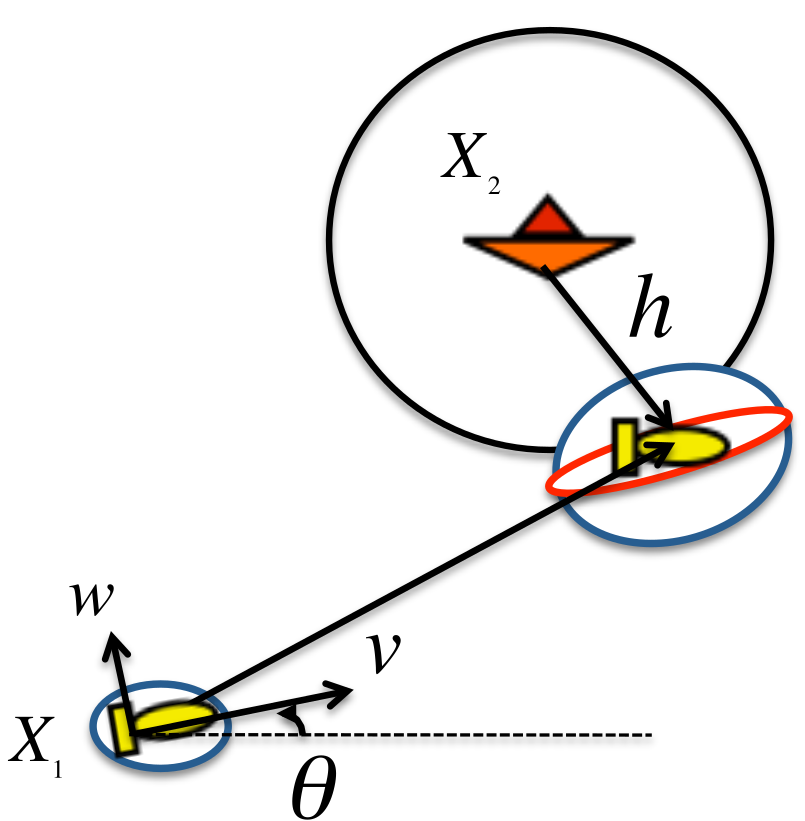
Cooperative Localization of Marine Vehicles using Nonlinear State Estimation. Georgios Papadopoulos, Maurice Fallon, John Leonard, Nicholas Patrikalakis, IEEE/RSJ Intl. Conf. on Intelligent Robots and Systems (IROS), 2010.
Paper
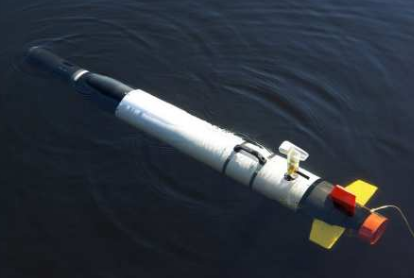
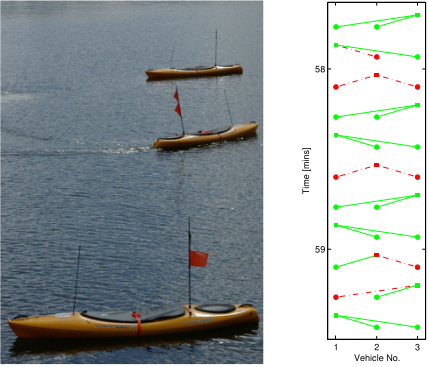
A Measurement Distribution Framework for Cooperative Navigation using multiple AUVs. Maurice Fallon, Georgios Papadopoulos, John Leonard, IEEE Intl. Conf. on Robotics and Automation (ICRA), 2010.
Paper
Cooperative AUV Navigation using a single surface craft. Maurice Fallon, Georgios Papadopoulos, John Leonard, Field and Service Robotics, 2010.
Paper
2009
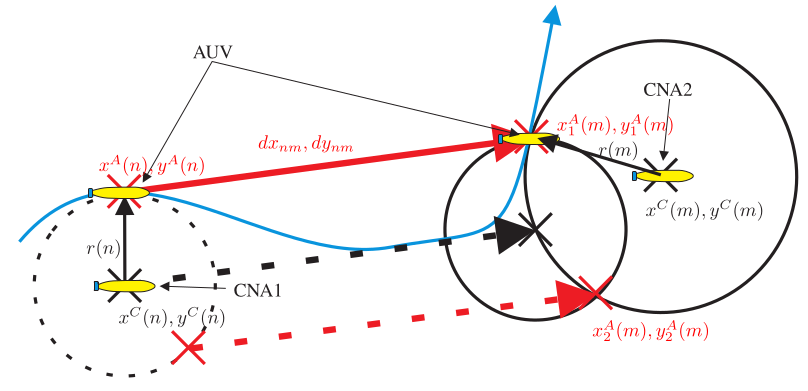
Cooperative Localization for Autonomous Underwater Vehicles. Alexander Bahr, John Leonard, Maurice Fallon, Intl. J. of Robotics Research, 2009.
Paper
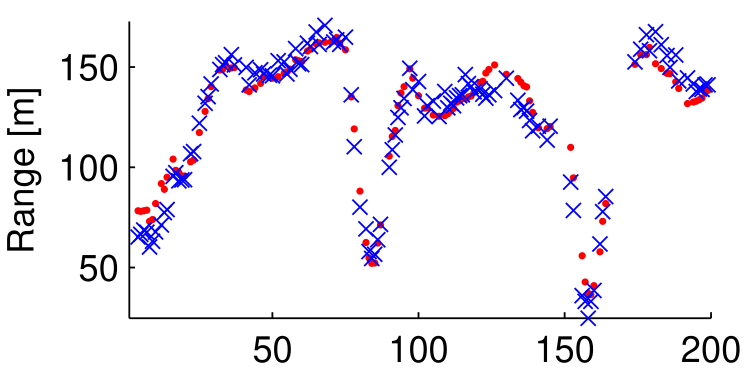
Cooperative AUV Navigation using a Single Surface Craft. Maurice Fallon, Georgios Papadopoulos, John Leonard, Field and Service Robotics (FSR), 2009.
Paper
2008
Acoustic Source Tracking using Sequential Monte Carlo. Maurice Fallon, University of Cambridge, 2008.
Paper
Multi Target Acoustic Source Tracking with an unknown and time varying number of targets. Maurice Fallon, Simon Godsill, Joint Workshop on Hands-free Speech Communication and Microphone Arrays (HSCMA), 2008.
Paper
2007
Multi-Target Acoustic Source Tracking Using Track Before Detect. Maurice Fallon, Simon Godsill, Workshop on Applications of Signal Processing to Audio and Acoustics (WASPAA), 2007.
Paper
2006
Joint Acoustic Source Location and Orientation Estimation Using Sequential Monte Carlo. Maurice Fallon, Simon Godsill, Andrew Blake, International Conference on Digital Audio Effects (DAFx), 2006.
Paper
2004
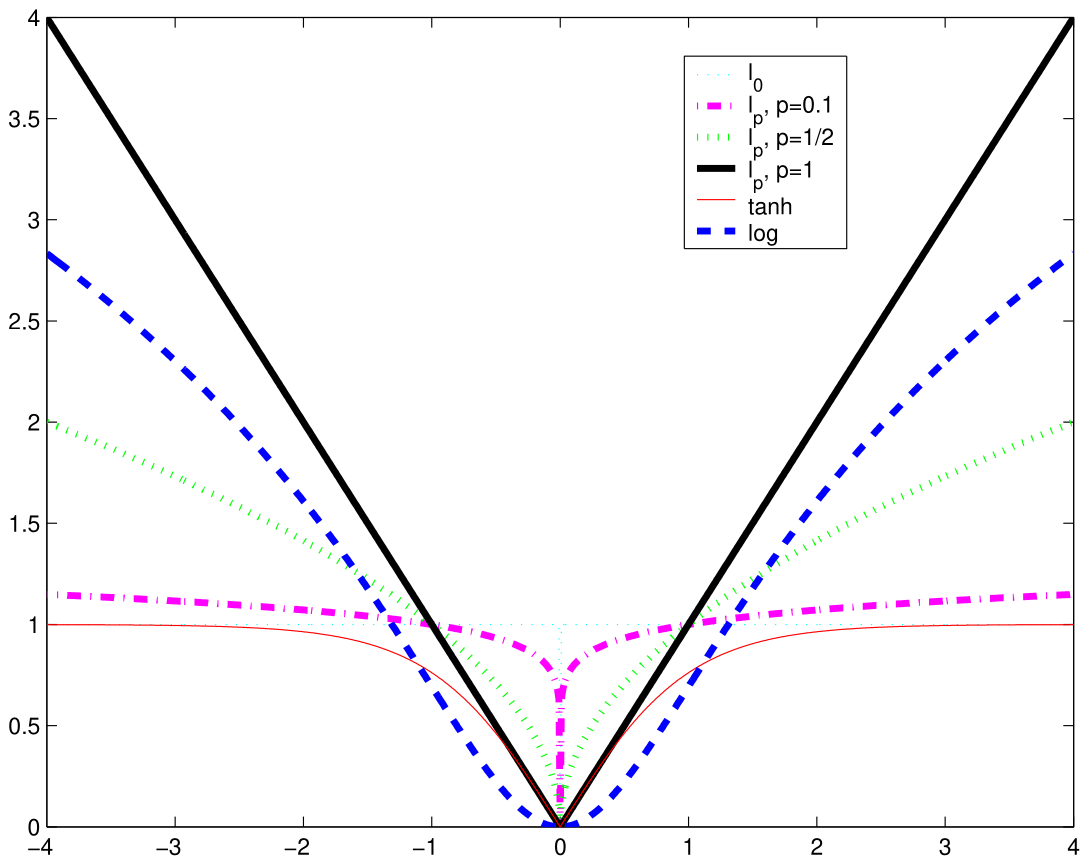
The Gini Index of Speech. Scott Rickard, Maurice Fallon, Conference on Information Sciences and Systems, 2004.
Paper